

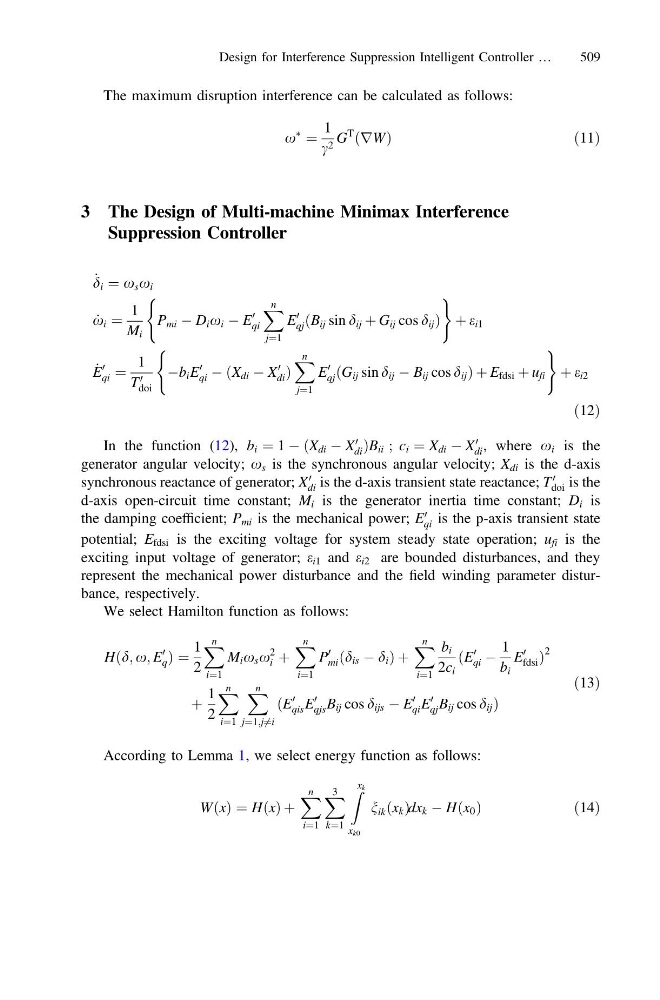
The maximum disruption interference can be calculated as follows:
x
Ã
¼
1
c 2 G
T
ðrWÞ
ð 11Þ
3 The Design of Multi-machine Minimax Interference
Suppression Controller
_
d i ¼ x s x i
_
x i ¼
1
M i
P mi À D i x i À E
0
qi
X n
j¼1
E
0
qj ðB ij sin d ij þ G ij cos d ij Þ
(
)
þ e i1
_
E
0
qi ¼
1
T 0
doi
Àb i E
0
qi À ðX di À X
0
di Þ
X n
j¼1
E
0
qj ðG ij sin d ij À B ij cos d ij Þ þ E fdsi þ u fi
(
)
þ e i2
ð12Þ
In the function (12), b i ¼ 1 À ðX di À X
0
di ÞB ii ; c i ¼ X di À X
0
di , where x i is the
generator angular velocity; x s is the synchronous angular velocity; X di is the d-axis
synchronous reactance of generator; X
0
di is the d-axis transient state reactance; T
0
doi is the
d-axis open-circuit time constant; M i is the generator inertia time constant; D i is
the damping coefficient; P mi is the mechanical power; E
0
qi is the p-axis transient state
potential; E fdsi is the exciting voltage for system steady state operation; u fi is the
exciting input voltage of generator; e i1 and e i2 are bounded disturbances, and they
represent the mechanical power disturbance and the field winding parameter disturbance, respectively.
We select Hamilton function as follows:
Hðd; x; E
0
q Þ ¼
1
2
X n
i¼1
M i x s x
2
i þ
X n
i¼1
P
0
mi ðd is À d i Þ þ
X n
i¼1
b i
2c i
ðE
0
qi À
1
b i
E
0
fdsi Þ
2
þ
1
2
X n
i¼1
X n
j¼1;j6 ¼i
ðE
0
qis E
0
qjs B ij cos d ijs À E
0
qi E
0
qj B ij cos d ij Þ
ð13Þ
According to Lemma 1, we select energy function as follows:
WðxÞ ¼ HðxÞ þ
X n
i¼1
X 3
k¼1
Z x k
x k0
n ik x k
ð Þdx k À Hðx 0 Þ
ð 14Þ
Design for Interference Suppression Intelligent Controller …
509