

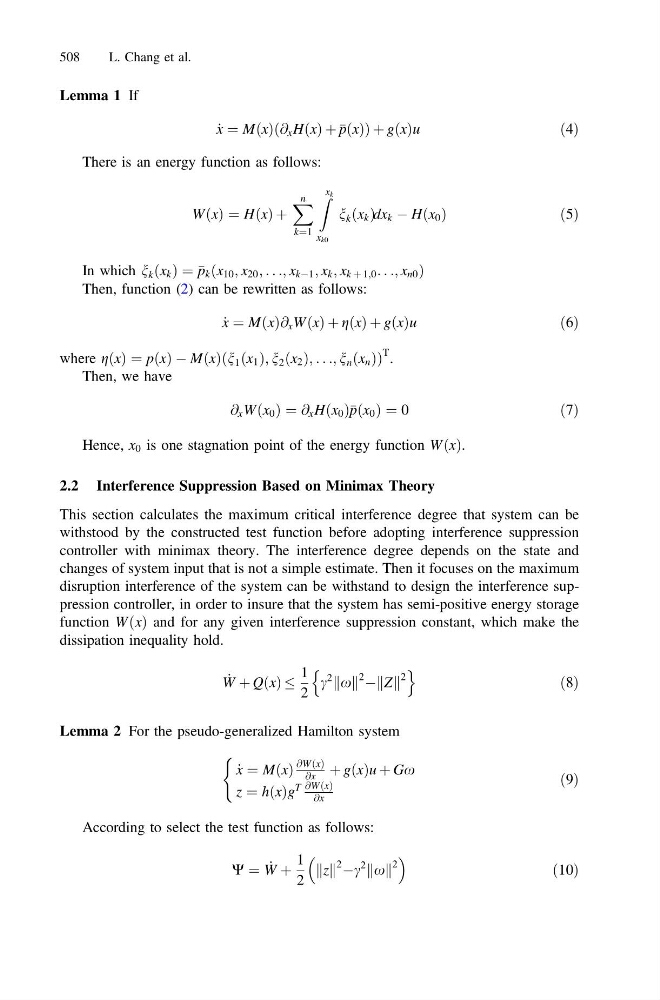
Lemma 1 If
_
x ¼ MðxÞð@ x HðxÞ þ pðxÞÞ þ gðxÞu
ð4Þ
There is an energy function as follows:
WðxÞ ¼ HðxÞ þ
X n
k¼1
Z x k
x k0
n k x k
ð Þdx k À Hðx 0 Þ
ð 5Þ
In which n k x k
ð Þ ¼ p k ðx 10 ; x 20 ; . . .; x kÀ1 ; x k ; x k þ 1;0 . . .; x n0 Þ
Then, function (2) can be rewritten as follows:
_
x ¼ M x
ð Þ@ x WðxÞ þ gðxÞ þ gðxÞu
ð6Þ
where gðxÞ ¼ pðxÞ À MðxÞðn 1 ðx 1 Þ; n 2 ðx 2 Þ; . . .; n n ðx n ÞÞ
T .
Then, we have
@ x W x 0
ð Þ ¼ @ x H x 0
ð Þ pðx 0 Þ ¼ 0
ð7Þ
Hence, x 0 is one stagnation point of the energy function WðxÞ.
2.2 Interference Suppression Based on Minimax Theory
This section calculates the maximum critical interference degree that system can be
withstood by the constructed test function before adopting interference suppression
controller with minimax theory. The interference degree depends on the state and
changes of system input that is not a simple estimate. Then it focuses on the maximum
disruption interference of the system can be withstand to design the interference suppression controller, in order to insure that the system has semi-positive energy storage
function W x
ð Þ and for any given interference suppression constant, which make the
dissipation inequality hold.
_
W þ QðxÞ
1
2
c
2
x
k k
2 À
n
Z
k k
2
o
ð8Þ
Lemma 2 For the pseudo-generalized Hamilton system
_
x ¼ MðxÞ
@WðxÞ
@x þ gðxÞu þ Gx
z ¼ hðxÞg
T @WðxÞ
@x
(
ð9Þ
According to select the test function as follows:
W ¼ _
W þ
1
2
z
k k
2 Àc
2
x
k k
2
ð10Þ
508
L. Chang et al.
_
x ¼ MðxÞð@ x HðxÞ þ pðxÞÞ þ gðxÞu
ð4Þ
There is an energy function as follows:
WðxÞ ¼ HðxÞ þ
X n
k¼1
Z x k
x k0
n k x k
ð Þdx k À Hðx 0 Þ
ð 5Þ
In which n k x k
ð Þ ¼ p k ðx 10 ; x 20 ; . . .; x kÀ1 ; x k ; x k þ 1;0 . . .; x n0 Þ
Then, function (2) can be rewritten as follows:
_
x ¼ M x
ð Þ@ x WðxÞ þ gðxÞ þ gðxÞu
ð6Þ
where gðxÞ ¼ pðxÞ À MðxÞðn 1 ðx 1 Þ; n 2 ðx 2 Þ; . . .; n n ðx n ÞÞ
T .
Then, we have
@ x W x 0
ð Þ ¼ @ x H x 0
ð Þ pðx 0 Þ ¼ 0
ð7Þ
Hence, x 0 is one stagnation point of the energy function WðxÞ.
2.2 Interference Suppression Based on Minimax Theory
This section calculates the maximum critical interference degree that system can be
withstood by the constructed test function before adopting interference suppression
controller with minimax theory. The interference degree depends on the state and
changes of system input that is not a simple estimate. Then it focuses on the maximum
disruption interference of the system can be withstand to design the interference suppression controller, in order to insure that the system has semi-positive energy storage
function W x
ð Þ and for any given interference suppression constant, which make the
dissipation inequality hold.
_
W þ QðxÞ
1
2
c
2
x
k k
2 À
n
Z
k k
2
o
ð8Þ
Lemma 2 For the pseudo-generalized Hamilton system
_
x ¼ MðxÞ
@WðxÞ
@x þ gðxÞu þ Gx
z ¼ hðxÞg
T @WðxÞ
@x
(
ð9Þ
According to select the test function as follows:
W ¼ _
W þ
1
2
z
k k
2 Àc
2
x
k k
2
ð10Þ
508
L. Chang et al.