

achieved good results in interference suppression and adaptive control of multi-machine
power system. However, in dealing with interference problems, it increases the conservatism of the system by reducing inequality.
The research findings of the author show the minimax theoretical control method
has a good effect on suppressing sudden large interference [7, 8], and it is mature for
the research on interference suppression of single-machine power system. Literature [9]
for TCSC single-machine infinite power system adopts the method of combining with
minimax and backstepping, puts forward a kind of effective output feedback control
method, and studies the robust stabilization problem of grid systems; literature [10]
imports minimax theory into the dissipative Hamilton system and designs the interference suppression controller for the TCSC single-machine infinite power system.
This paper focuses on modifying generalized Hamilton system-based minimax
theory for solving the interference suppression of multi-machine power systems.
Minimax method is used to deal with the interference item of the system, and it
estimates accurately the inflection of maximum interference on the system. Through the
construction of the index function and performance metrics, the conservatism of traditional interference processing methods has been improved.
2 Preliminary Knowledge
2.1 Pseudo-generalized Hamilton
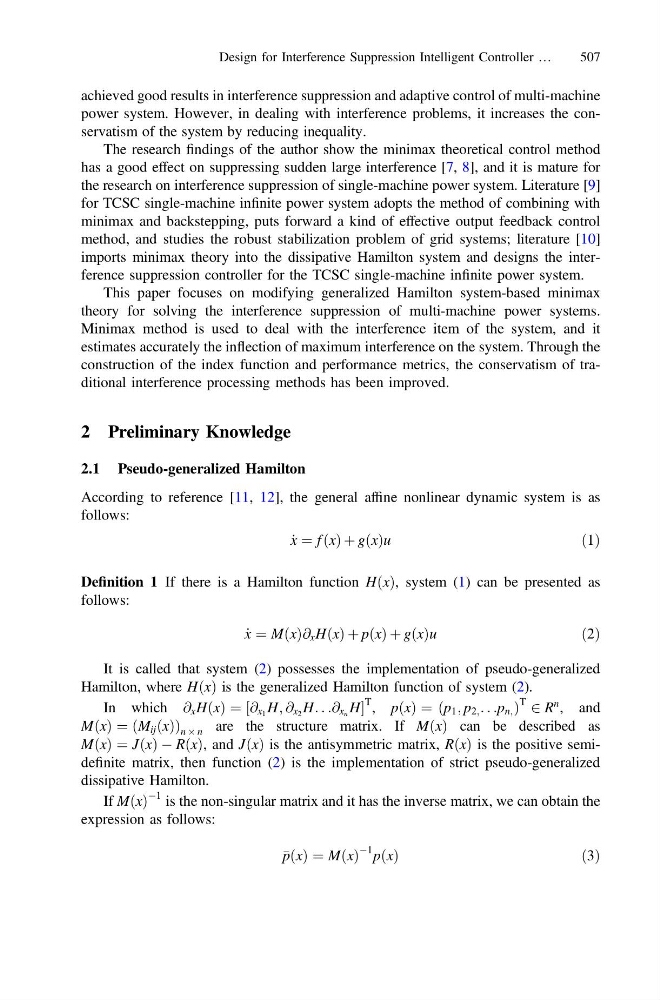
According to reference [11, 12], the general affine nonlinear dynamic system is as
follows:
_
x ¼ f ðxÞ þ gðxÞu
ð1Þ
Definition 1 If there is a Hamilton function HðxÞ, system (1) can be presented as
follows:
_
x ¼ MðxÞ@ x HðxÞ þ pðxÞ þ gðxÞu
ð2Þ
It is called that system (2) possesses the implementation of pseudo-generalized
Hamilton, where HðxÞ is the generalized Hamilton function of system (2).
In which @ x HðxÞ ¼ ½@ x 1 H; @ x 2 H. . .@ x n H
T , pðxÞ ¼ ðp 1 ; p 2; . . .p n; Þ
T 2 R
n , and
MðxÞ ¼ ðM ij ðxÞÞ n  n are the structure matrix. If MðxÞ can be described as
MðxÞ ¼ JðxÞ À RðxÞ, and JðxÞ is the antisymmetric matrix, RðxÞ is the positive semidefinite matrix, then function (2) is the implementation of strict pseudo-generalized
dissipative Hamilton.
If MðxÞ
À1 is the non-singular matrix and it has the inverse matrix, we can obtain the
expression as follows:
pðxÞ ¼ MðxÞ
À1 pðxÞ
ð 3Þ
Design for Interference Suppression Intelligent Controller …
507