

The outliers shown in the above figure correspond to the node grid coordinates, so the
two aircraft cannot simultaneously adopt the maneuvering mode to reach the
coordinates.
Similarly, for the flight conflict caused by the airspace limitation, the no-fly zone
grid is processed by the numerical labeling method in the initialization process, and the
form is the same as above, as shown in Fig. 3.
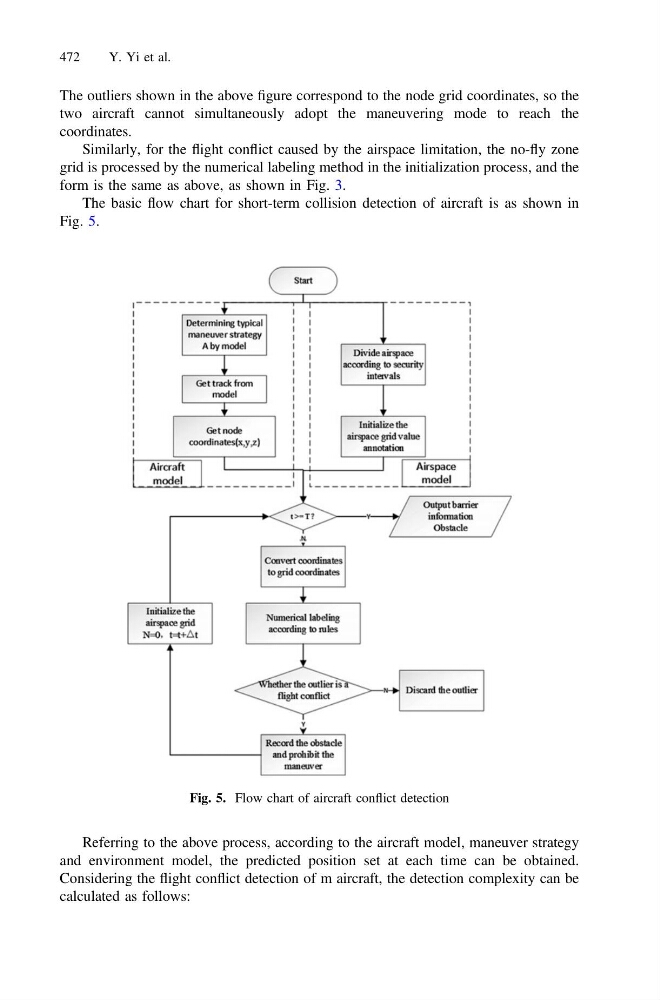
The basic flow chart for short-term collision detection of aircraft is as shown in
Fig. 5.
Referring to the above process, according to the aircraft model, maneuver strategy
and environment model, the predicted position set at each time can be obtained.
Considering the flight conflict detection of m aircraft, the detection complexity can be
calculated as follows:
Fig. 5. Flow chart of aircraft conflict detection
472
Y. Yi et al.