

In order to add nonlinear elements to the neural network, ReLU (modified linear
element) is adopted as the activation function, and its expression is
ReLUx ¼
x if x[ 0
0 if x 0
ð2Þ
Thus, the output O
l
ð Þ
i of the ith unit in the I layer is
O
ðlÞ
i ¼ ReLU
X n
j¼1
w
ðlÀ1Þ
ij
x j þ b
ðlÀ1Þ
i
!
ð3Þ
where B is the bias value, and b
ðlÀ1Þ
i
is the l−1 bias value in the i layer.
The loss of a single sample adopts mean square error, and its expression is
loss =
X k
i¼1
p i À t i
ð
Þ
2
ð4Þ
where p i is the sample predicted value, t i is the sample real value, and k is the number
of neurons in the output layer.
2.2 Estimation Method for Simulated Sea Clutter Data
The fully connected neural network is adopted, and the processed sea clutter data
(simulation data) is taken as input data. After the multilayer fully connected neural
network, the influence parameters of the sea clutter model were obtained, and then the
parameters were substituted into the sea clutter model as the cost function feedback to
carry out the reverse propagation, adjust the weight, and re-input the sea clutter data for
training and calculation. The higher the fitting degree is, the more consistent the data is
with the model. Until the parameters are more ideal, the parameters of the clutter model
.
.
.
.
.
.
input layer
hidden layer
output layer
.
.
.
.
.
.
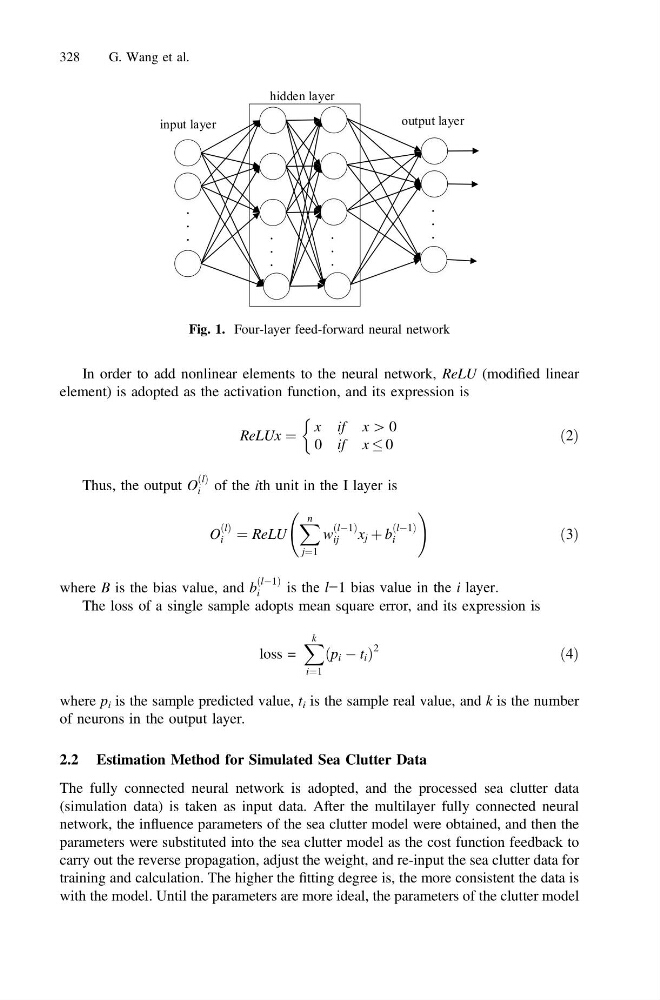
Fig. 1. Four-layer feed-forward neural network
328
G. Wang et al.