

different filters to convolve each channel to obtain the output of the corresponding
channel and then blends the information. The depth-separable convolutional layer
reduces the required parameters over ordinary convolutional layers. The ordinary
convolution layer considers the channel and the area simultaneously, while the depthseparable convolution layer considers only the area first, and then considers the channel
to achieve the separation of the channel and the area.
GRU is a type of recurrent neural network (RNN). This structure appeared in 2014
[14] and its performance on polyphonic music modeling and speech signal modeling
[15–17] is comparable to that of long short-term memory (LSTM) [18], but it uses
fewer parameters as lacking an output gate [19, 20]. Since the three gates in LSTM
contribute differently to improve their learning ability, the contribution of small gates
and their corresponding weights can be omitted, which can simplify the neural network
structure and improve its learning efficiency. GRU is an algorithm based on the above
concept, and its corresponding loop unit contains only two gates: the update gate and
the reset gate, wherein the function of the reset gate is similar to the input gate of the
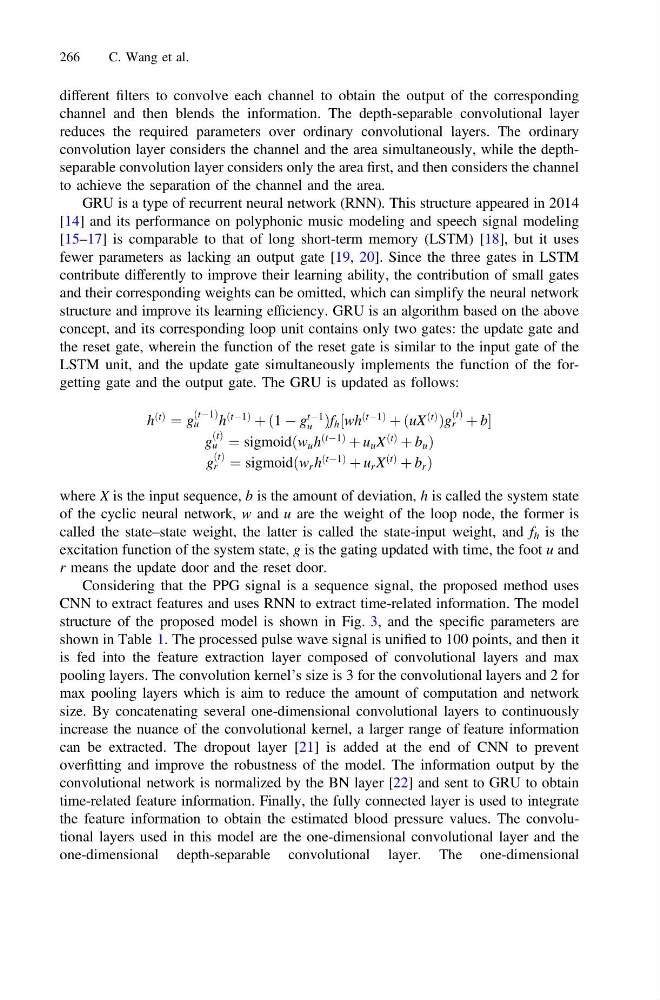
LSTM unit, and the update gate simultaneously implements the function of the forgetting gate and the output gate. The GRU is updated as follows:
h
ðtÞ
¼ g
ðtÀ1Þ
u
h
ðtÀ1Þ
þ ð1 À g
tÀ1
u Þf h ½wh
ðtÀ1Þ
þ ðuX
ðtÞ
Þg
ðtÞ
r þ b
g
ðtÞ
u ¼ sigmoidðw u h
ðtÀ1Þ
þ u u X
ðtÞ
þ b u Þ
g
ðtÞ
r ¼ sigmoidðw r h
ðtÀ1Þ
þ u r X
ðtÞ
þ b r Þ
where X is the input sequence, b is the amount of deviation, h is called the system state
of the cyclic neural network, w and u are the weight of the loop node, the former is
called the state–state weight, the latter is called the state-input weight, and f h is the
excitation function of the system state, g is the gating updated with time, the foot u and
r means the update door and the reset door.
Considering that the PPG signal is a sequence signal, the proposed method uses
CNN to extract features and uses RNN to extract time-related information. The model
structure of the proposed model is shown in Fig. 3, and the specific parameters are
shown in Table 1. The processed pulse wave signal is unified to 100 points, and then it
is fed into the feature extraction layer composed of convolutional layers and max
pooling layers. The convolution kernel’s size is 3 for the convolutional layers and 2 for
max pooling layers which is aim to reduce the amount of computation and network
size. By concatenating several one-dimensional convolutional layers to continuously
increase the nuance of the convolutional kernel, a larger range of feature information
can be extracted. The dropout layer [21] is added at the end of CNN to prevent
overfitting and improve the robustness of the model. The information output by the
convolutional network is normalized by the BN layer [22] and sent to GRU to obtain
time-related feature information. Finally, the fully connected layer is used to integrate
the feature information to obtain the estimated blood pressure values. The convolutional layers used in this model are the one-dimensional convolutional layer and the
one-dimensional depth-separable convolutional layer. The one-dimensional
266
C. Wang et al.