

to be adjusted when the KL distance exceeds the confidence limit for that the difference
between training and the current data block model is large. The KL distance of other
data blocks is close to 0, that is, there is no change between data blocks.
Therefore, the proposed algorithm is of great significance for anomaly detection
and adaptive data flow partitioning.
Table 1. Parameters of GRBM
Number of visible
100
Number of hidden
10
Epochs
1000
Learning_rate
0.1
Weight_decay
1
cd_steps
1
Momentum
0.5
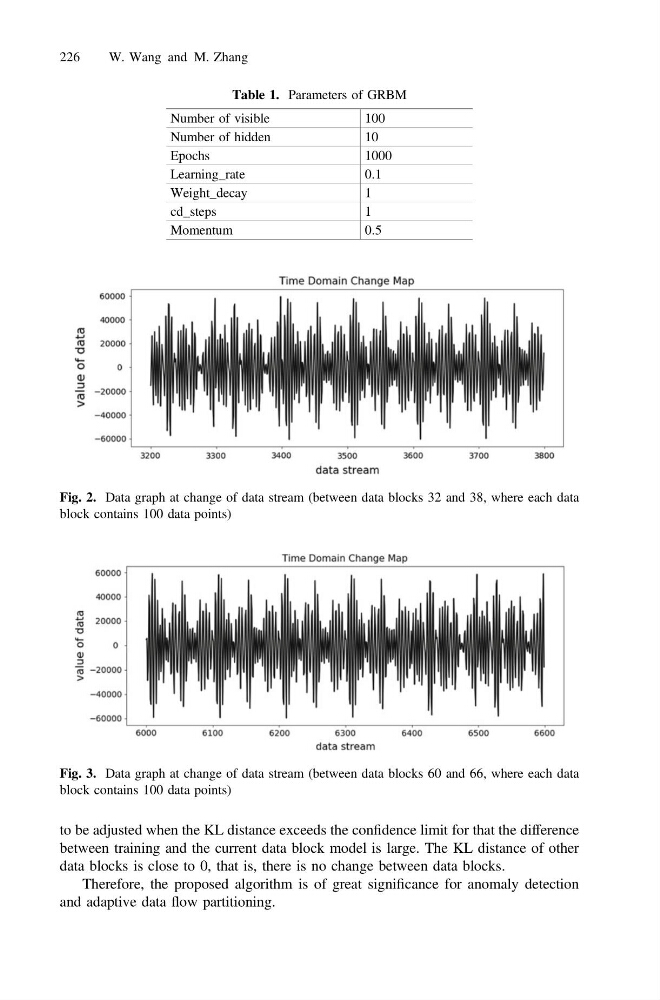
Fig. 2. Data graph at change of data stream (between data blocks 32 and 38, where each data
block contains 100 data points)
Fig. 3. Data graph at change of data stream (between data blocks 60 and 66, where each data
block contains 100 data points)
226
W. Wang and M. Zhang