

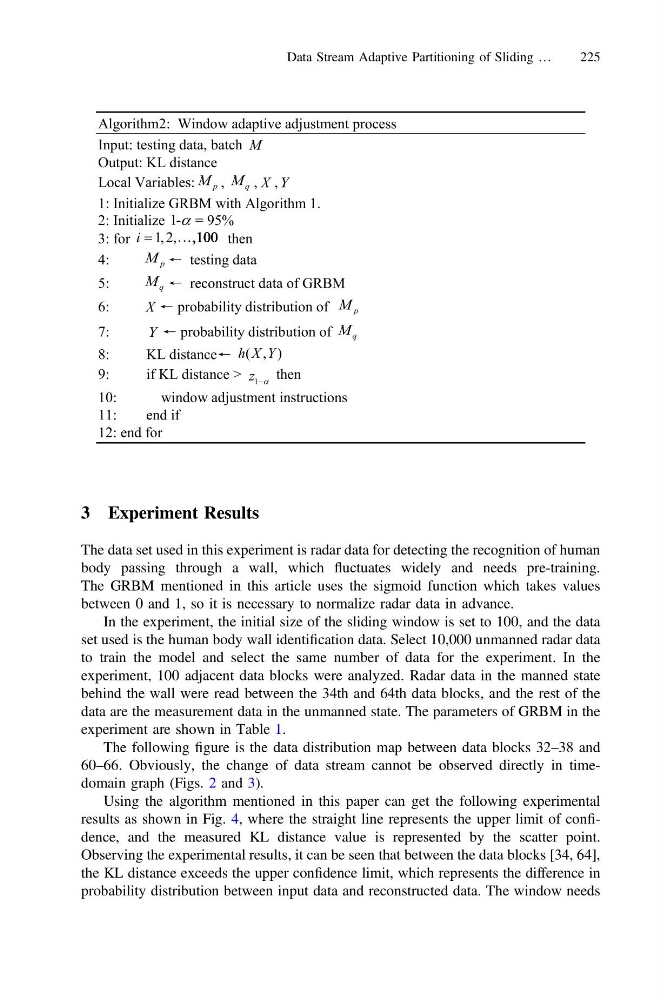
3 Experiment Results
The data set used in this experiment is radar data for detecting the recognition of human
body passing through a wall, which fluctuates widely and needs pre-training.
The GRBM mentioned in this article uses the sigmoid function which takes values
between 0 and 1, so it is necessary to normalize radar data in advance.
In the experiment, the initial size of the sliding window is set to 100, and the data
set used is the human body wall identification data. Select 10,000 unmanned radar data
to train the model and select the same number of data for the experiment. In the
experiment, 100 adjacent data blocks were analyzed. Radar data in the manned state
behind the wall were read between the 34th and 64th data blocks, and the rest of the
data are the measurement data in the unmanned state. The parameters of GRBM in the
experiment are shown in Table 1.
The following figure is the data distribution map between data blocks 32–38 and
60–66. Obviously, the change of data stream cannot be observed directly in timedomain graph (Figs. 2 and 3).
Using the algorithm mentioned in this paper can get the following experimental
results as shown in Fig. 4, where the straight line represents the upper limit of confidence, and the measured KL distance value is represented by the scatter point.
Observing the experimental results, it can be seen that between the data blocks [34, 64],
the KL distance exceeds the upper confidence limit, which represents the difference in
probability distribution between input data and reconstructed data. The window needs
Data Stream Adaptive Partitioning of Sliding …
225