

166
2 Variational Problems with Fixed Boundaries
or it is abbreviated to
F u −
n
i=1
∂
∂ x i
F u x i = 0
(2.8.22)
This type of equations are often met in the equilibrium problems of elastic
dynamics.
In Eq. (2.8.21), taking n = 4, let x = x 1 , y = x 2 , z = x 3 , t = x 4 , then there is
the functional
J [u(x, y, z, t)] =
t 1
t 0
˚
V
F(x, y, z, t, u, u x , u y , u z , u t )dxdydzdt
(2.8.23)
Its extremal function satisfies the Ostrogradsky equation
F u −
∂
∂ x
F u x −
∂
∂ y
F u y −
∂
∂z
F u z −
∂
∂t
F u t = 0
(2.8.24)
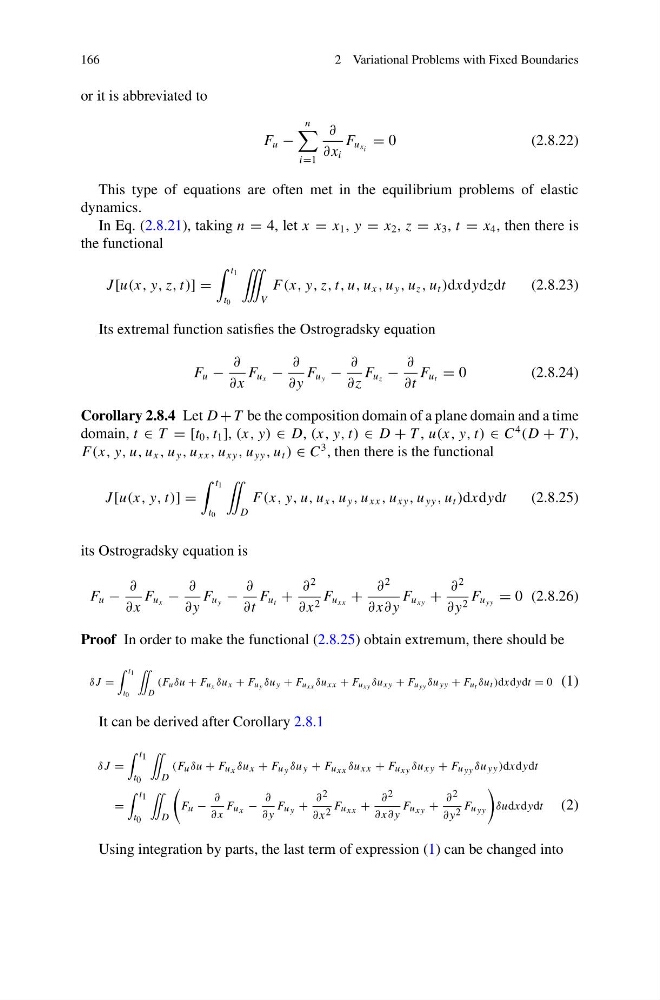
Corollary 2.8.4 Let D + T be the composition domain of a plane domain and a time
domain, t ∈ T = [t 0 , t 1 ], (x, y) ∈ D, (x, y, t) ∈ D + T , u(x, y, t) ∈ C
4
(D + T ),
F(x, y, u, u x , u y , u xx , u xy , u yy , u t ) ∈ C
3 , then there is the functional
J [u(x, y, t)] =
t 1
t 0
¨
D
F(x, y, u, u x , u y , u xx , u xy , u yy , u t )dxdydt
(2.8.25)
its Ostrogradsky equation is
F u −
∂
∂ x
F u x −
∂
∂ y
F u y −
∂
∂t
F u t +
∂
2
∂ x 2 F u xx +
∂
2
∂ x∂ y
F u xy +
∂
2
∂ y 2 F u yy = 0 (2.8.26)
Proof In order to make the functional (2.8.25) obtain extremum, there should be
δ J =
t1
t0
¨
D
(F u δu + F ux δu x + F u y δu y + F uxx δu xx + F uxy δu xy + F u yy δu yy + F ut δu t )dxdydt = 0 (1)
It can be derived after Corollary 2.8.1
δ J =
t 1
t 0
¨
D
(F u δu + F u x δu x + F u y δu y + F u xx δu xx + F u xy δu xy + F u yy δu yy )dxdydt
=
t 1
t 0
¨
D
F u −
∂
∂ x
F u x −
∂
∂ y
F u y +
∂ 2
∂ x 2 F u xx +
∂ 2
∂ x∂ y
F u xy +
∂ 2
∂ y 2 F u yy
δudxdydt
(2)
Using integration by parts, the last term of expression (1) can be changed into