

38
4 Riemann Spaces and Tensors
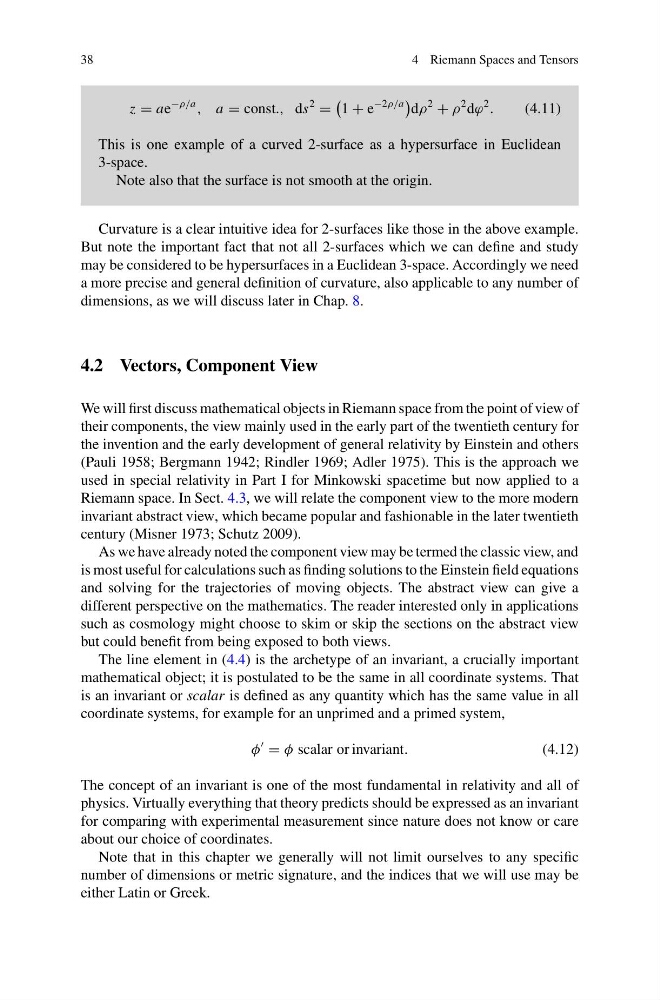
z = ae
−ρ/a
, a = const., ds
2
=
1 + e
−2ρ/a
dρ
2
+ ρ
2 dϕ
2
.
(4.11)
This is one example of a curved 2-surface as a hypersurface in Euclidean
3-space.
Note also that the surface is not smooth at the origin.
Curvature is a clear intuitive idea for 2-surfaces like those in the above example.
But note the important fact that not all 2-surfaces which we can define and study
may be considered to be hypersurfaces in a Euclidean 3-space. Accordingly we need
a more precise and general definition of curvature, also applicable to any number of
dimensions, as we will discuss later in Chap. 8.
4.2 Vectors, Component View
We will first discuss mathematical objects in Riemann space from the point of view of
their components, the view mainly used in the early part of the twentieth century for
the invention and the early development of general relativity by Einstein and others
(Pauli 1958; Bergmann 1942; Rindler 1969; Adler 1975). This is the approach we
used in special relativity in Part I for Minkowski spacetime but now applied to a
Riemann space. In Sect. 4.3, we will relate the component view to the more modern
invariant abstract view, which became popular and fashionable in the later twentieth
century (Misner 1973; Schutz 2009).
As we have already noted the component view may be termed the classic view, and
is most useful for calculations such as finding solutions to the Einstein field equations
and solving for the trajectories of moving objects. The abstract view can give a
different perspective on the mathematics. The reader interested only in applications
such as cosmology might choose to skim or skip the sections on the abstract view
but could benefit from being exposed to both views.
The line element in (4.4) is the archetype of an invariant, a crucially important
mathematical object; it is postulated to be the same in all coordinate systems. That
is an invariant or scalar is defined as any quantity which has the same value in all
coordinate systems, for example for an unprimed and a primed system,
φ
= φ scalar or invariant.
(4.12)
The concept of an invariant is one of the most fundamental in relativity and all of
physics. Virtually everything that theory predicts should be expressed as an invariant
for comparing with experimental measurement since nature does not know or care
about our choice of coordinates.
Note that in this chapter we generally will not limit ourselves to any specific
number of dimensions or metric signature, and the indices that we will use may be
either Latin or Greek.