

d ¼
1
2
l þ l
T
À
Á
,
ð6Þ
w ¼
1
2
l À l
T
À
Á :
ð7Þ
There is an important relationship between the spatial velocity gradient l and the
time derivative of the deformation gradient tensor _
F:
l ¼ _
FF
À1
:
ð8Þ
In order to further characterize the deformation, the strain tensors related to either
the reference or the current configuration are introduced here. With respect to the
reference configuration Ω 0 , two material strain tensors are defined [5]:
C ¼ F
T F,
ð9Þ
E ¼
1
2
C À I
ð
Þ,
ð10Þ
where C is the right Cauchy-Green deformation tensor and E is the Green-Lagrange
strain tensor. For the current configuration Ω, one can define two spatial strain
sensors [5]:
b ¼ FF
T ,
ð11Þ
e ¼
1
2
I À b
À1
À
Á
,
ð12Þ
where b is the left Cauchy-Green deformation tensor and e is the Euler-Almansi
strain tensor. For completeness, the deformation rates defined by the time derivatives
of the strain tensors in Eqs. (9)–(12) are given as follows [5]:
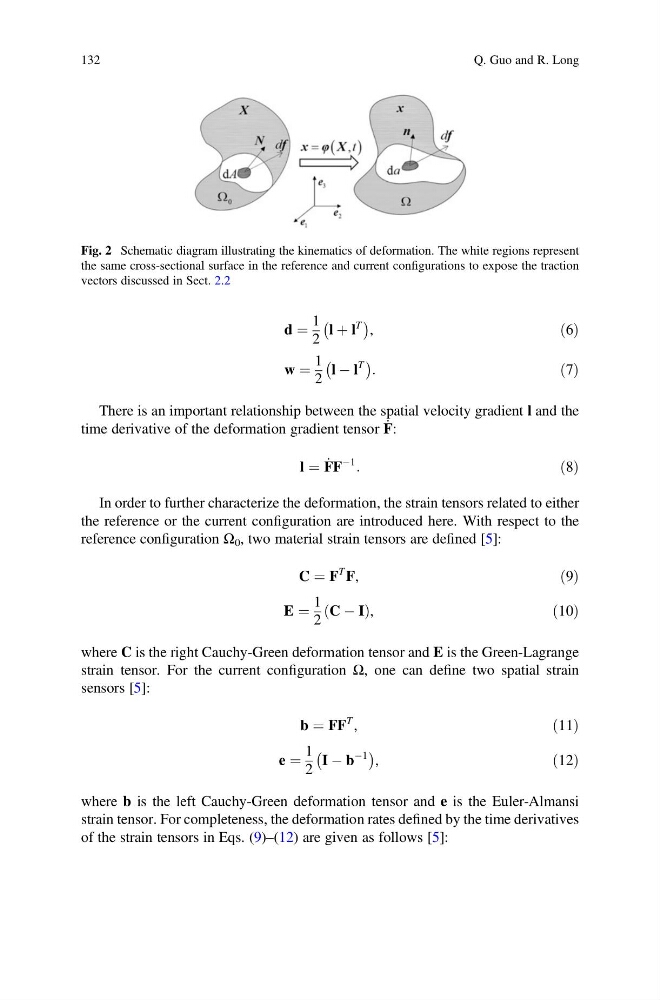
Fig. 2 Schematic diagram illustrating the kinematics of deformation. The white regions represent
the same cross-sectional surface in the reference and current configurations to expose the traction
vectors discussed in Sect. 2.2
132
Q. Guo and R. Long
1
2
l þ l
T
À
Á
,
ð6Þ
w ¼
1
2
l À l
T
À
Á :
ð7Þ
There is an important relationship between the spatial velocity gradient l and the
time derivative of the deformation gradient tensor _
F:
l ¼ _
FF
À1
:
ð8Þ
In order to further characterize the deformation, the strain tensors related to either
the reference or the current configuration are introduced here. With respect to the
reference configuration Ω 0 , two material strain tensors are defined [5]:
C ¼ F
T F,
ð9Þ
E ¼
1
2
C À I
ð
Þ,
ð10Þ
where C is the right Cauchy-Green deformation tensor and E is the Green-Lagrange
strain tensor. For the current configuration Ω, one can define two spatial strain
sensors [5]:
b ¼ FF
T ,
ð11Þ
e ¼
1
2
I À b
À1
À
Á
,
ð12Þ
where b is the left Cauchy-Green deformation tensor and e is the Euler-Almansi
strain tensor. For completeness, the deformation rates defined by the time derivatives
of the strain tensors in Eqs. (9)–(12) are given as follows [5]:
Fig. 2 Schematic diagram illustrating the kinematics of deformation. The white regions represent
the same cross-sectional surface in the reference and current configurations to expose the traction
vectors discussed in Sect. 2.2
132
Q. Guo and R. Long