

9.6 Forced Vibration of Flexural Member Subjected to Ground Motion Excitation
385
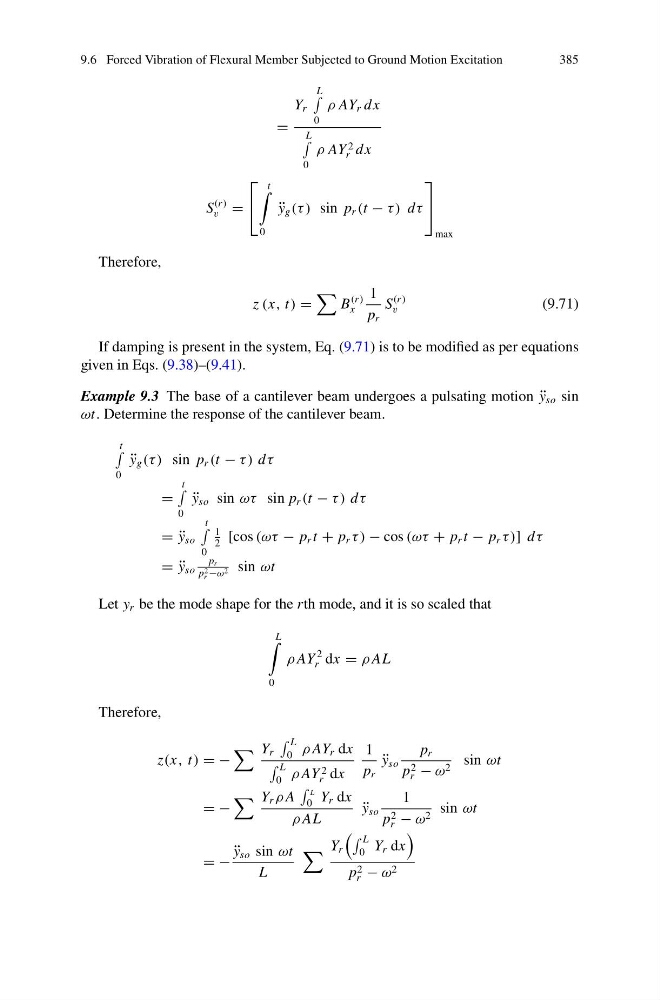
=
Y r
L
0
ρ AY r dx
L
0
ρ AY 2
r dx
S
(r )
v =
⎡
⎣
t
0
¨
y g (τ ) sin p r (t − τ ) dτ
⎤
⎦
max
Therefore,
z (x, t) =
B
(r )
x
1
p r
S
(r )
v
(9.71)
If damping is present in the system, Eq. (9.71) is to be modified as per equations
given in Eqs. (9.38)–(9.41).
Example 9.3 The base of a cantilever beam undergoes a pulsating motion ¨
y so sin
ωt. Determine the response of the cantilever beam.
t
0
¨
y g (τ ) sin p r (t − τ ) dτ
=
t
0
¨
y so sin ωτ sin p r (t − τ ) dτ
= ¨
y so
t
0
1
2
[cos (ωτ − p r t + p r τ ) − cos (ωτ + p r t − p r τ )] dτ
= ¨
y so
p r
p 2
r −ω 2 sin ωt
Let y r be the mode shape for the rth mode, and it is so scaled that
L
0
ρ AY
2
r dx = ρ AL
Therefore,
z(x, t) = −
Y r
L
0 ρ AY r dx
L
0 ρ AY 2
r dx
1
p r
¨
y so
p r
p 2
r − ω 2 sin ωt
= −
Y r ρ A
L
0 Y r dx
ρ AL
¨
y so
1
p 2
r − ω 2 sin ωt
= −
¨
y so sin ωt
L
Y r
L
0 Y r dx
p 2
r − ω 2