

9.3 Forced Vibration of the Shear Beam Under Ground Motion Excitation
377
z(x, t) = −
Y r (x)
L
0 ρ AY r dx
L
0 ρ AY 2
r dx
1
p r
t
0
¨
y g (τ ) sin p r (t − τ ) dτ
(9.34)
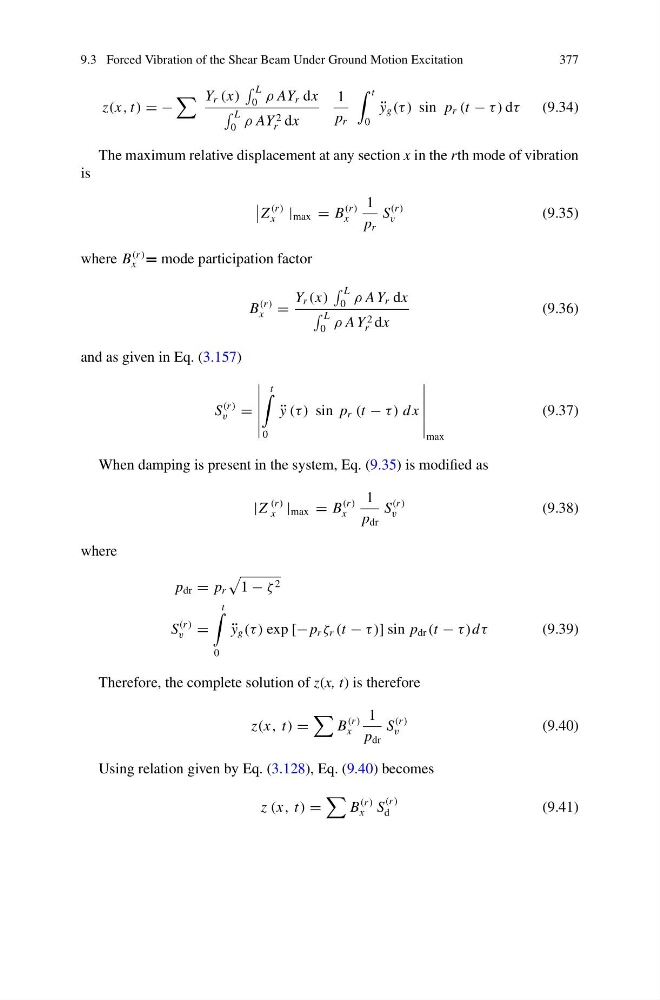
The maximum relative displacement at any section x in the rth mode of vibration
is
Z
(r )
x | max = B
(r )
x
1
p r
S
(r )
v
(9.35)
where B
(r )
x = mode participation factor
B
(r )
x =
Y r (x)
L
0 ρ A Y r dx
L
0 ρ A Y 2
r dx
(9.36)
and as given in Eq. (3.157)
S
(r )
v =
t
0
¨
y (τ ) sin p r (t − τ ) dx
max
(9.37)
When damping is present in the system, Eq. (9.35) is modified as
|Z
(r )
x | max = B
(r )
x
1
p dr
S
(r )
v
(9.38)
where
p dr = p r
1 − ζ 2
S
(r )
v =
t
0
¨
y g (τ ) exp [− p r ζ r (t − τ )] sin p dr (t − τ )dτ
(9.39)
Therefore, the complete solution of z(x, t) is therefore
z(x, t) =
B
(r )
x
1
p dr
S
(r )
v
(9.40)
Using relation given by Eq. (3.128), Eq. (9.40) becomes
z (x, t) =
B
(r )
x S
(r )
d
(9.41)