

376
9 Forced Vibration of Continuous Systems
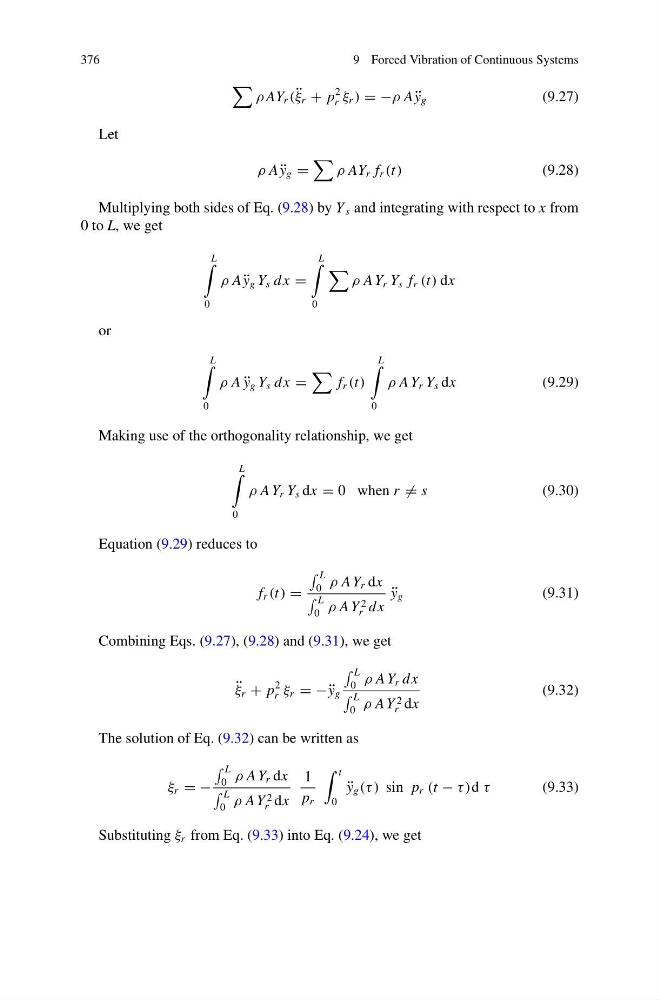
ρ AY r ( ¨
ξ r + p
2
r ξ r ) = −ρ A ¨
y g
(9.27)
Let
ρ A ¨
y g =
ρ AY r f r (t)
(9.28)
Multiplying both sides of Eq. (9.28) by Y s and integrating with respect to x from
0 to L, we get
L
0
ρ A ¨
y g Y s dx =
L
0
ρ A Y r Y s f r (t) dx
or
L
0
ρ A ¨
y g Y s dx =
f r (t)
L
0
ρ A Y r Y s dx
(9.29)
Making use of the orthogonality relationship, we get
L
0
ρ A Y r Y s dx = 0 when r = s
(9.30)
Equation (9.29) reduces to
f r (t) =
L
0 ρ A Y r dx
L
0 ρ A Y 2
r dx
¨
y g
(9.31)
Combining Eqs. (9.27), (9.28) and (9.31), we get
¨
ξ r + p
2
r ξ r = − ¨
y g
L
0 ρ A Y r dx
L
0 ρ A Y 2
r dx
(9.32)
The solution of Eq. (9.32) can be written as
ξ r = −
L
0 ρ A Y r dx
L
0 ρ A Y 2
r dx
1
p r
t
0
¨
y g (τ ) sin p r (t − τ )d τ
(9.33)
Substituting ξ r from Eq. (9.33) into Eq. (9.24), we get