

8.18 Transverse Vibration of Rectangular Thin Plates
365
σ x , σ y and σ z are the normal stresses in the x-, y- and z-directions and τ xy , τ yz and
τ zx are the shearing stress components.
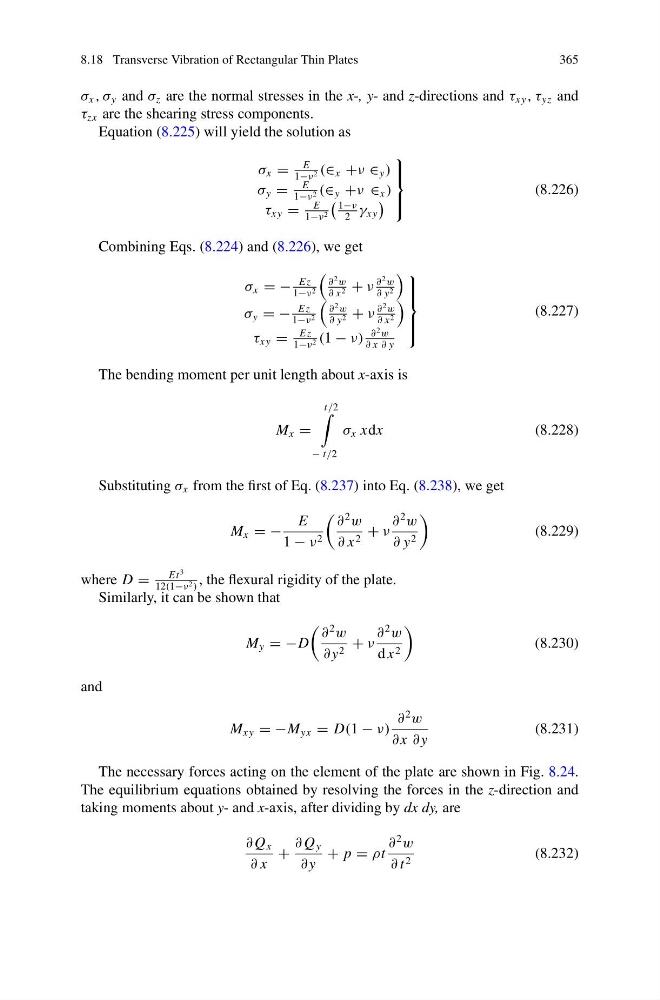
Equation (8.225) will yield the solution as
σ x =
E
1−ν 2 (∈ x +ν ∈ y )
σ y =
E
1−ν 2 (∈ y +ν ∈ x )
τ xy =
E
1−ν 2
1−ν
2
γ xy
⎫
⎪ ⎬
⎪ ⎭
(8.226)
Combining Eqs. (8.224) and (8.226), we get
σ x = −
Ez
1−ν 2
∂
2 w
∂ x 2 + ν
∂
2 w
∂ y 2
σ y = −
Ez
1−ν 2
∂
2 w
∂ y 2 + ν
∂
2 w
∂ x 2
τ xy =
Ez
1−ν 2 (1 − ν)
∂
2 w
∂ x ∂ y
⎫
⎪ ⎪ ⎬
⎪ ⎪ ⎭
(8.227)
The bending moment per unit length about x-axis is
M x =
t/2
− t/2
σ x xdx
(8.228)
Substituting σ x from the first of Eq. (8.237) into Eq. (8.238), we get
M x = −
E
1 − ν 2
∂
2
w
∂ x 2 + ν
∂
2
w
∂ y 2
(8.229)
where D =
Et
3
12(1−ν 2 )
, the flexural rigidity of the plate.
Similarly, it can be shown that
M y = −D
∂
2
w
∂ y 2 + ν
∂
2
w
d x 2
(8.230)
and
M xy = −M yx = D(1 − ν)
∂
2
w
∂ x ∂ y
(8.231)
The necessary forces acting on the element of the plate are shown in Fig. 8.24.
The equilibrium equations obtained by resolving the forces in the z-direction and
taking moments about y- and x-axis, after dividing by dx dy, are
∂ Q x
∂ x
+
∂ Q y
∂ y
+ p = ρt
∂
2
w
∂ t 2
(8.232)