

268
7 Forced Vibration Analysis of Multiple Degrees of Freedom System
¯
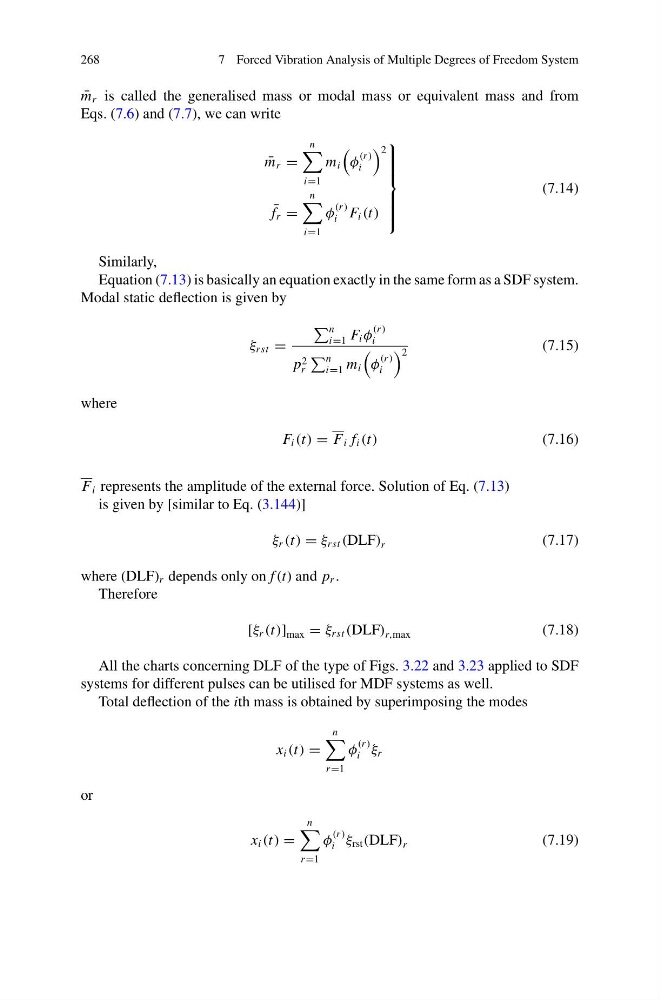
m r is called the generalised mass or modal mass or equivalent mass and from
Eqs. (7.6) and (7.7), we can write
¯
m r =
n
i=1
m i
φ
(r )
i
2
¯
f r =
n
i=1
φ
(r )
i F i (t)
⎫
⎪ ⎪ ⎪ ⎪ ⎬
⎪ ⎪ ⎪ ⎪ ⎭
(7.14)
Similarly,
Equation (7.13) is basically an equation exactly in the same form as a SDF system.
Modal static deflection is given by
ξ rst =
n
i=1 F i φ
(r )
i
p 2
r
n
i=1 m i
φ
(r )
i
2
(7.15)
where
F i (t) = F i f i (t)
(7.16)
F i represents the amplitude of the external force. Solution of Eq. (7.13)
is given by [similar to Eq. (3.144)]
ξ r (t) = ξ rst (DLF) r
(7.17)
where (DLF) r depends only on f (t) and p r .
Therefore
[ξ r (t)] max = ξ rst (DLF) r,max
(7.18)
All the charts concerning DLF of the type of Figs. 3.22 and 3.23 applied to SDF
systems for different pulses can be utilised for MDF systems as well.
Total deflection of the ith mass is obtained by superimposing the modes
x i (t) =
n
r =1
φ
(r )
i ξ r
or
x i (t) =
n
r =1
φ
(r )
i ξ rst (DLF) r
(7.19)