

170
5 Vibration of Two Degrees of Freedom System
W = 150 N, L 1 = 1.35 m, L 2 = 1.65 m, k 1 = 360 N/m
k 2 = 370 N/m, J c = 27 m
4
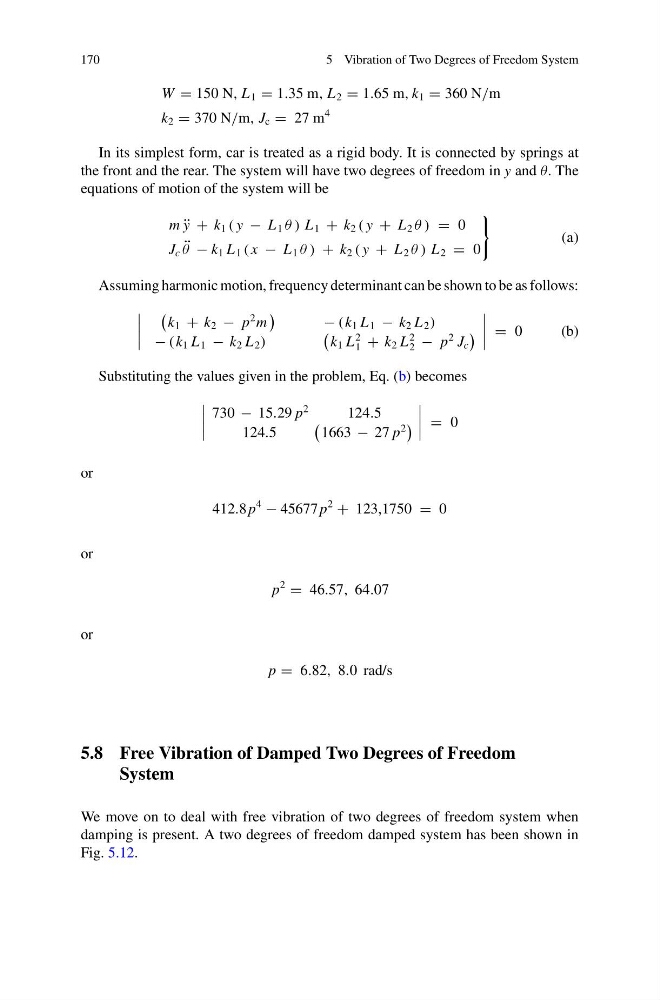
In its simplest form, car is treated as a rigid body. It is connected by springs at
the front and the rear. The system will have two degrees of freedom in y and θ. The
equations of motion of the system will be
m ¨
y + k 1 ( y − L 1 θ ) L 1 + k 2 ( y + L 2 θ ) = 0
J c ¨
θ − k 1 L 1 ( x − L 1 θ ) + k 2 ( y + L 2 θ ) L 2 = 0
(a)
Assuming harmonic motion, frequency determinant can be shown to be as follows:
k 1 + k 2 − p
2 m
− ( k 1 L 1 − k 2 L 2 )
− ( k 1 L 1 − k 2 L 2 )
k 1 L
2
1 + k 2 L
2
2 − p
2 J c
= 0
(b)
Substituting the values given in the problem, Eq. (b) becomes
730 − 15.29 p
2
124.5
124.5
1663 − 27 p
2
= 0
or
412.8 p
4
− 45677 p
2
+ 123,1750 = 0
or
p
2
= 46.57, 64.07
or
p = 6.82, 8.0 rad/s
5.8 Free Vibration of Damped Two Degrees of Freedom
System
We move on to deal with free vibration of two degrees of freedom system when
damping is present. A two degrees of freedom damped system has been shown in
Fig. 5.12.