

Fluid Dynamics in Deformable Microchannels
163
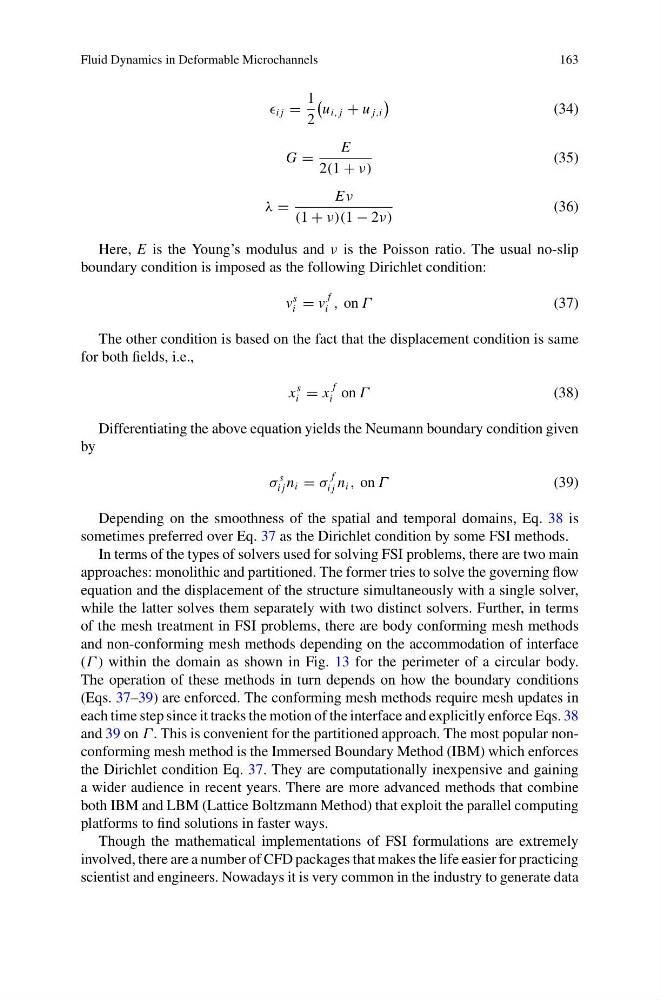
i j =
1
2
u i, j + u j,i
(34)
G =
E
2(1 + ν)
(35)
λ =
Eν
(1 + ν)(1 − 2ν)
(36)
Here, E is the Young’s modulus and ν is the Poisson ratio. The usual no-slip
boundary condition is imposed as the following Dirichlet condition:
v
s
i = v
f
i , on Γ
(37)
The other condition is based on the fact that the displacement condition is same
for both fields, i.e.,
x
s
i = x
f
i on Γ
(38)
Differentiating the above equation yields the Neumann boundary condition given
by
σ
s
i j n i = σ
f
i j n i , on Γ
(39)
Depending on the smoothness of the spatial and temporal domains, Eq. 38 is
sometimes preferred over Eq. 37 as the Dirichlet condition by some FSI methods.
In terms of the types of solvers used for solving FSI problems, there are two main
approaches: monolithic and partitioned. The former tries to solve the governing flow
equation and the displacement of the structure simultaneously with a single solver,
while the latter solves them separately with two distinct solvers. Further, in terms
of the mesh treatment in FSI problems, there are body conforming mesh methods
and non-conforming mesh methods depending on the accommodation of interface
(Γ ) within the domain as shown in Fig. 13 for the perimeter of a circular body.
The operation of these methods in turn depends on how the boundary conditions
(Eqs. 37–39) are enforced. The conforming mesh methods require mesh updates in
each time step since it tracks the motion of the interface and explicitly enforce Eqs. 38
and 39 on Γ . This is convenient for the partitioned approach. The most popular nonconforming mesh method is the Immersed Boundary Method (IBM) which enforces
the Dirichlet condition Eq. 37. They are computationally inexpensive and gaining
a wider audience in recent years. There are more advanced methods that combine
both IBM and LBM (Lattice Boltzmann Method) that exploit the parallel computing
platforms to find solutions in faster ways.
Though the mathematical implementations of FSI formulations are extremely
involved, there are a number of CFD packages that makes the life easier for practicing
scientist and engineers. Nowadays it is very common in the industry to generate data