

�
�
�
�
�
�
150
Chapter 3. Wave optics
Since the numerator is the momentum, we identify the group velocity with the classical particle velocity. In this sense, the motion
of the group corresponds to the classical particle motion.
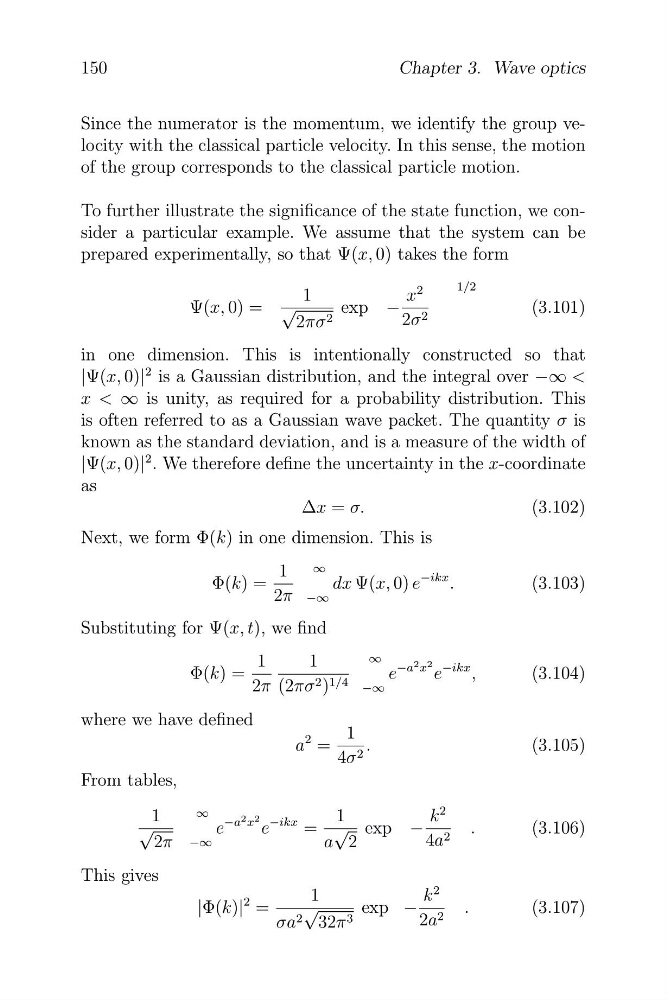
To further illustrate the significance of the state function, we consider a particular example. We assume that the system can be
prepared experimentally, so that Ψ(x, 0) takes the form
1/2
2
1
x
Ψ(x, 0) = √
exp −
(3.101)
2σ 2
2πσ 2
in one dimension. This is intentionally constructed so that
|Ψ(x, 0)|
2 is a Gaussian distribution, and the integral over −∞ <
x < ∞ is unity, as required for a probability distribution. This
is often referred to as a Gaussian wave packet. The quantity σ is
known as the standard deviation, and is a measure of the width of
|Ψ(x, 0)|
2 . We therefore define the uncertainty in the x-coordinate
as
Δx = σ.
(3.102)
Next, we form Φ(k) in one dimension. This is
1
Φ(k) =
∞
dx Ψ(x, 0) e
−ikx .
(3.103)
2π −∞
Substituting for Ψ(x, t), we find
∞
1
1
2 2
−a x −ikx
Φ(k) =
e
e
,
(3.104)
2π (2πσ 2 ) 1/4 −∞
where we have defined
a
2 =
1 .
(3.105)
4σ 2
From tables,
∞
2
k
2
1
1
−a x −ikx
√
e
2
e
= √ exp − 2 .
(3.106)
2π −∞
a 2
4a
This gives
1
k
2
|Φ(k)|
2 =
√
exp −
.
(3.107)
σa 2 32π 3
2a 2
�
�
�
�
�
150
Chapter 3. Wave optics
Since the numerator is the momentum, we identify the group velocity with the classical particle velocity. In this sense, the motion
of the group corresponds to the classical particle motion.
To further illustrate the significance of the state function, we consider a particular example. We assume that the system can be
prepared experimentally, so that Ψ(x, 0) takes the form
1/2
2
1
x
Ψ(x, 0) = √
exp −
(3.101)
2σ 2
2πσ 2
in one dimension. This is intentionally constructed so that
|Ψ(x, 0)|
2 is a Gaussian distribution, and the integral over −∞ <
x < ∞ is unity, as required for a probability distribution. This
is often referred to as a Gaussian wave packet. The quantity σ is
known as the standard deviation, and is a measure of the width of
|Ψ(x, 0)|
2 . We therefore define the uncertainty in the x-coordinate
as
Δx = σ.
(3.102)
Next, we form Φ(k) in one dimension. This is
1
Φ(k) =
∞
dx Ψ(x, 0) e
−ikx .
(3.103)
2π −∞
Substituting for Ψ(x, t), we find
∞
1
1
2 2
−a x −ikx
Φ(k) =
e
e
,
(3.104)
2π (2πσ 2 ) 1/4 −∞
where we have defined
a
2 =
1 .
(3.105)
4σ 2
From tables,
∞
2
k
2
1
1
−a x −ikx
√
e
2
e
= √ exp − 2 .
(3.106)
2π −∞
a 2
4a
This gives
1
k
2
|Φ(k)|
2 =
√
exp −
.
(3.107)
σa 2 32π 3
2a 2