

19 Electro-Mechanical Co-Simulation of a 6-DOF …
247
y
adams_sub
Z_Step
Z_Sine
Y_Sine
X_Step
X_Sine
W_Sine
W
V_Step
V_Sine
U_Step
U_Sine
U6
U5
U4
U3
U2
U1
X
Y
Z
U
V
W
L1_VP
L2_VP
L3_VP
L4_VP
L5_VP
L6_VP
L1
e1
L2
e2
L3
e3
L4
e4
L5
e5
L6
e6
fcn
Reverse Solver
Output_Z
Output_Y
Output_X
Output_W
Output_V
Output_U
Output_Strut6Length
Output_Strut5Length
Output_Strut4Length
Output_Strut3Length
Output_Strut2Length
Output_Strut1Length
L6
L5
L4
L3
L2
L1
1
s
Integrator5
1
s
Integrator4
1
s
Integrator3
1
s
Integrator2
1
s
Integrator1
1
s
Integrator
Input_Z
ki
Gain9
kp
Gain8
ki
Gain7
kp
Gain6
ki
Gain5
kp
Gain4
ki
Gain3
kp
Gain2
ki
Gain11
kp
Gain10
ki
Gain1
kp
Gain
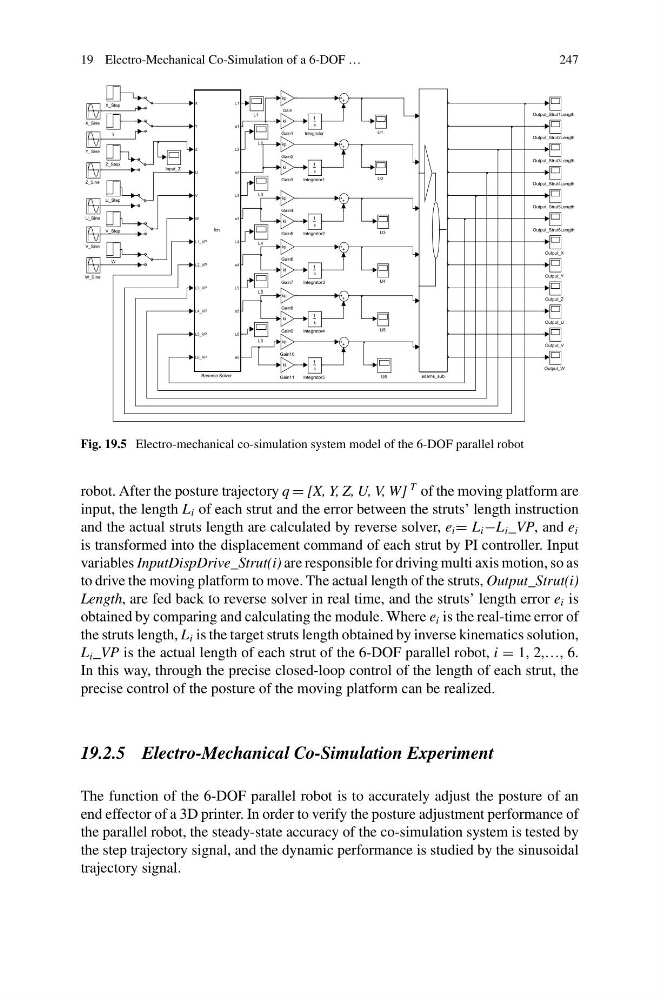
Fig. 19.5 Electro-mechanical co-simulation system model of the 6-DOF parallel robot
robot. After the posture trajectory q = [X, Y, Z, U, V, W]
T of the moving platform are
input, the length L i of each strut and the error between the struts’ length instruction
and the actual struts length are calculated by reverse solver, e i = L i −L i _VP, and e i
is transformed into the displacement command of each strut by PI controller. Input
variables InputDispDrive_Strut(i) are responsible for driving multi axis motion, so as
to drive the moving platform to move. The actual length of the struts, Output_Strut(i)
Length, are fed back to reverse solver in real time, and the struts’ length error e i is
obtained by comparing and calculating the module. Where e i is the real-time error of
the struts length, L i is the target struts length obtained by inverse kinematics solution,
L i _VP is the actual length of each strut of the 6-DOF parallel robot, i = 1, 2,…, 6.
In this way, through the precise closed-loop control of the length of each strut, the
precise control of the posture of the moving platform can be realized.
19.2.5 Electro-Mechanical Co-Simulation Experiment
The function of the 6-DOF parallel robot is to accurately adjust the posture of an
end effector of a 3D printer. In order to verify the posture adjustment performance of
the parallel robot, the steady-state accuracy of the co-simulation system is tested by
the step trajectory signal, and the dynamic performance is studied by the sinusoidal
trajectory signal.