

212
L. Zhao et al.
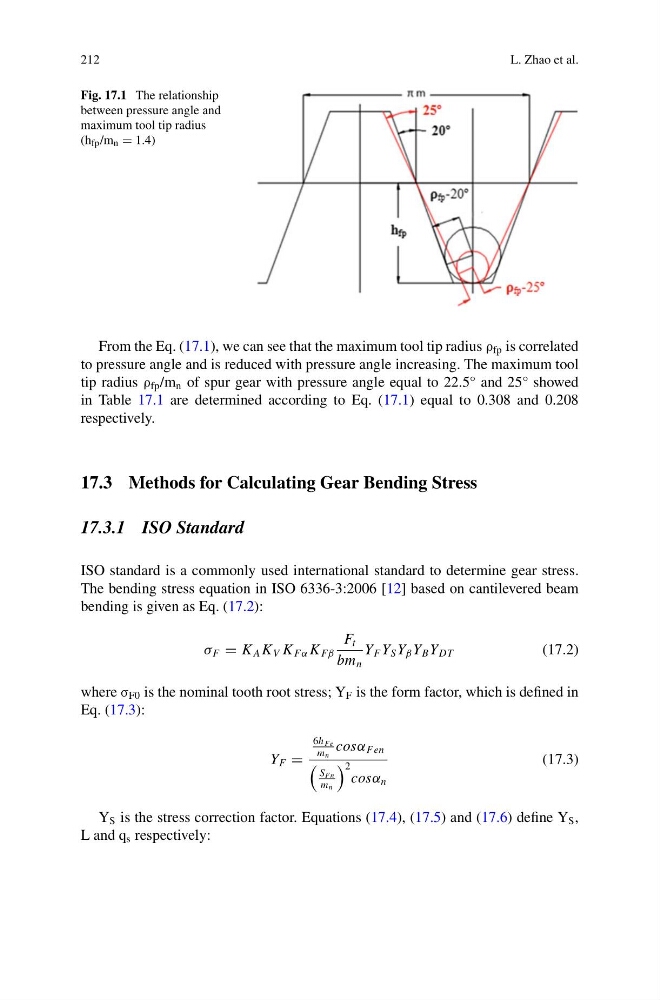
Fig. 17.1 The relationship
between pressure angle and
maximum tool tip radius
(h fp /m n = 1.4)
From the Eq. (17.1), we can see that the maximum tool tip radius ρ fp is correlated
to pressure angle and is reduced with pressure angle increasing. The maximum tool
tip radius ρ fp /m n of spur gear with pressure angle equal to 22.5° and 25° showed
in Table 17.1 are determined according to Eq. (17.1) equal to 0.308 and 0.208
respectively.
17.3 Methods for Calculating Gear Bending Stress
17.3.1 ISO Standard
ISO standard is a commonly used international standard to determine gear stress.
The bending stress equation in ISO 6336-3:2006 [12] based on cantilevered beam
bending is given as Eq. (17.2):
σ F = K A K V K Fα K Fβ
F t
bm n
Y F Y S Y β Y B Y DT
(17.2)
where σ F0 is the nominal tooth root stress; Y F is the form factor, which is defined in
Eq. (17.3):
Y F =
6h Fe
m n
cosα Fen
S Fn
m n
2
cosα n
(17.3)
Y S is the stress correction factor. Equations (17.4), (17.5) and (17.6) define Y S ,
L and q s respectively: