

3.2 Fundamental Principles for Mathematical Models Development
99
E k =
1
2
mυ
2
=
1
2
m
l
dθ
dt
2
=
1
2
ml
2
dθ
dt
2
,
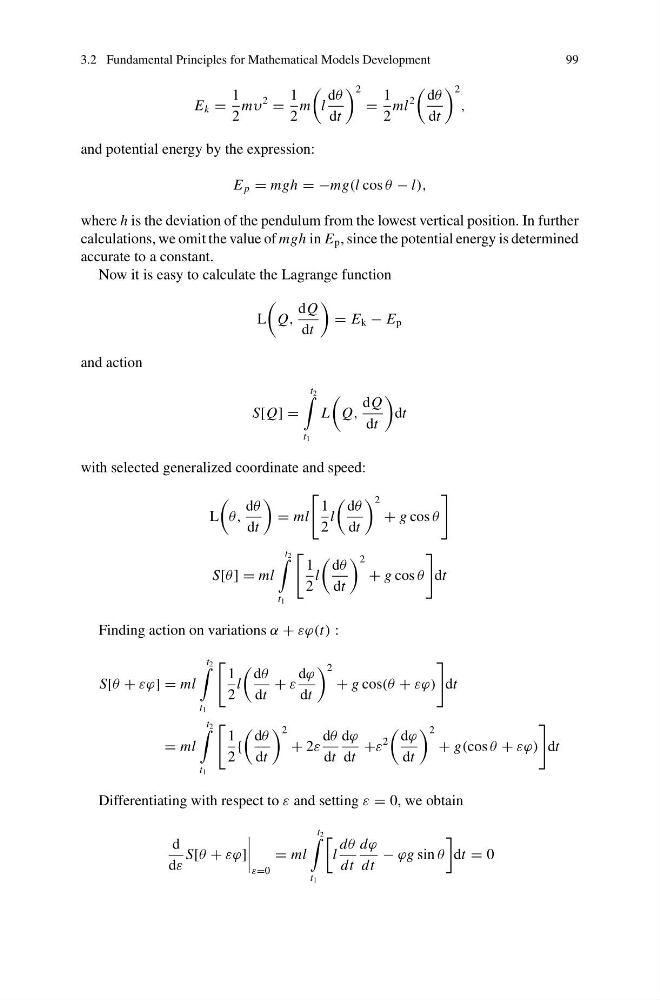
and potential energy by the expression:
E p = mgh = −mg(l cos θ − l),
where h is the deviation of the pendulum from the lowest vertical position. In further
calculations, we omit the value of mgh in E p , since the potential energy is determined
accurate to a constant.
Now it is easy to calculate the Lagrange function
L
Q,
dQ
dt
= E k − E p
and action
S[Q] =
t 2
t 1
L
Q,
dQ
dt
dt
with selected generalized coordinate and speed:
L
θ,
dθ
dt
= ml
1
2
l
dθ
dt
2
+ g cos θ
S[θ ] = ml
t 2
t 1
1
2
l
dθ
dt
2
+ g cos θ
dt
Finding action on variations α + εϕ(t) :
S[θ + εϕ] = ml
t 2
t 1
1
2
l
dθ
dt
+ ε
dϕ
dt
2
+ g cos(θ + εϕ)
dt
= ml
t 2
t 1
1
2
{
dθ
dt
2
+ 2ε
dθ
dt
dϕ
dt
+ε
2
dϕ
dt
2
+ g(cos θ + εϕ)
dt
Differentiating with respect to ε and setting ε = 0, we obtain
d
dε
S[θ + εϕ]
ε=0
= ml
t 2
t 1
l
dθ
dt
dϕ
dt
− ϕg sin θ
dt = 0