

180
P v
v v
v v
P v
v v
P
v
v v
v v
v v
k
k
k
k
w
C
R
C
R
C
R
R
R
F
C
F
and
( ) =
−
−
⋅
≤ ≤
≤ ≤
≤
≥
0
(10.5)
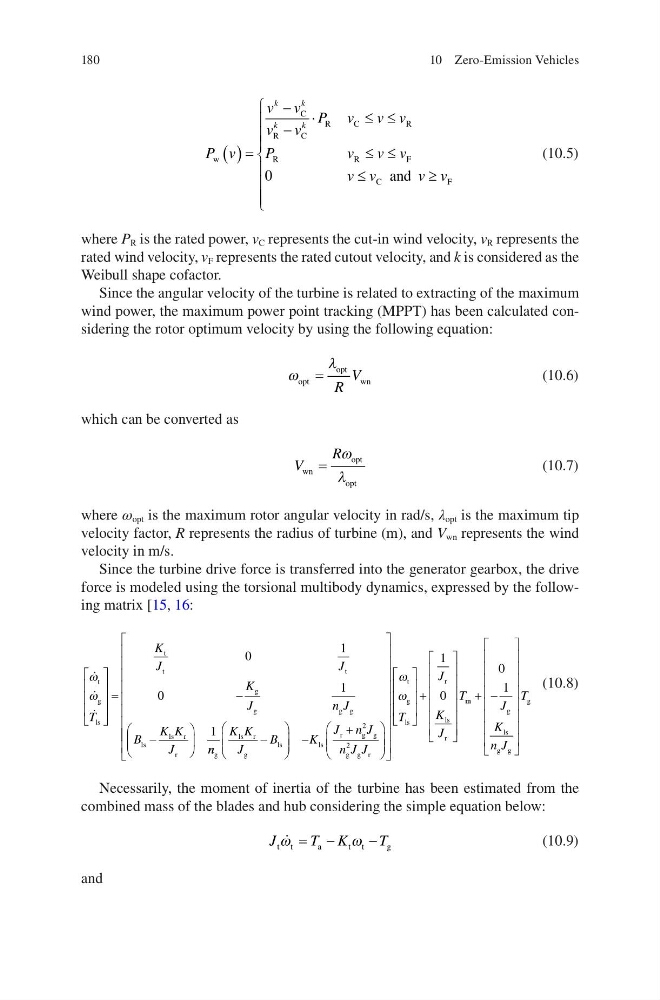
where P R is the rated power, v C represents the cut-in wind velocity, v R represents the
rated wind velocity, v F represents the rated cutout velocity, and k is considered as the
Weibull shape cofactor.
Since the angular velocity of the turbine is related to extracting of the maximum
wind power, the maximum power point tracking (MPPT) has been calculated considering the rotor optimum velocity by using the following equation:
ω
λ
opt
opt
wn
= R
V
(10.6)
which can be converted as
V
R
wn
opt
opt
=
ω
λ
(10.7)
where ω opt is the maximum rotor angular velocity in rad/s, λ opt is the maximum tip
velocity factor, R represents the radius of turbine (m), and V wn represents the wind
velocity in m/s.
Since the turbine drive force is transferred into the generator gearbox, the drive
force is modeled using the torsional multibody dynamics, expressed by the following matrix [15, 16:
ω
ω
t
g
ls
t
t
t
g
g
g g
ls
ls r
r
T
K
J
J
K
J
n J
B
K K
J
=
−
−
0
1
0
1
1
n n
K K
J
B
K
J n J
n J J
g
ls r
g
ls
ls
r
g g
g g r
−
−
+
2
2
+
ω
ω
t
g
ls
r
ls
r
T
J
K
J
T
1
0 m m
g
ls
g g
g
+ −
0
1
J
K
n J
T
(10.8)
Necessarily, the moment of inertia of the turbine has been estimated from the
combined mass of the blades and hub considering the simple equation below:
J
T K
T
t t
a
t t
g
ω
ω
= −
−
(10.9)
and
10 Zero-Emission Vehicles
P v
v v
v v
P v
v v
P
v
v v
v v
v v
k
k
k
k
w
C
R
C
R
C
R
R
R
F
C
F
and
( ) =
−
−
⋅
≤ ≤
≤ ≤
≤
≥
0
(10.5)
where P R is the rated power, v C represents the cut-in wind velocity, v R represents the
rated wind velocity, v F represents the rated cutout velocity, and k is considered as the
Weibull shape cofactor.
Since the angular velocity of the turbine is related to extracting of the maximum
wind power, the maximum power point tracking (MPPT) has been calculated considering the rotor optimum velocity by using the following equation:
ω
λ
opt
opt
wn
= R
V
(10.6)
which can be converted as
V
R
wn
opt
opt
=
ω
λ
(10.7)
where ω opt is the maximum rotor angular velocity in rad/s, λ opt is the maximum tip
velocity factor, R represents the radius of turbine (m), and V wn represents the wind
velocity in m/s.
Since the turbine drive force is transferred into the generator gearbox, the drive
force is modeled using the torsional multibody dynamics, expressed by the following matrix [15, 16:
ω
ω
t
g
ls
t
t
t
g
g
g g
ls
ls r
r
T
K
J
J
K
J
n J
B
K K
J
=
−
−
0
1
0
1
1
n n
K K
J
B
K
J n J
n J J
g
ls r
g
ls
ls
r
g g
g g r
−
−
+
2
2
+
ω
ω
t
g
ls
r
ls
r
T
J
K
J
T
1
0 m m
g
ls
g g
g
+ −
0
1
J
K
n J
T
(10.8)
Necessarily, the moment of inertia of the turbine has been estimated from the
combined mass of the blades and hub considering the simple equation below:
J
T K
T
t t
a
t t
g
ω
ω
= −
−
(10.9)
and
10 Zero-Emission Vehicles