

192
4 Problems in Soft Tissue Biomechanics
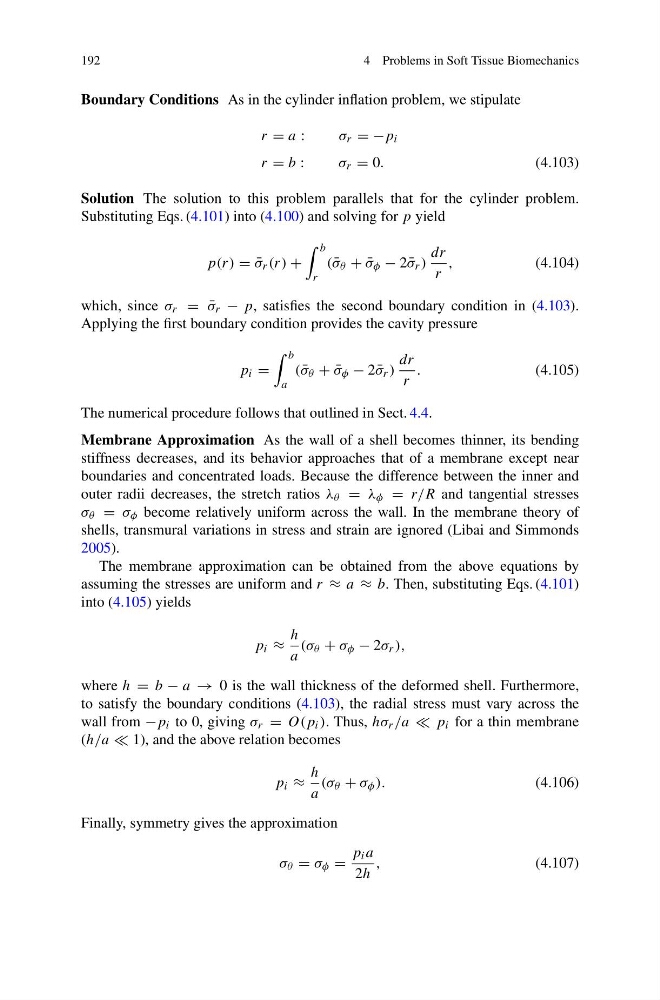
Boundary Conditions As in the cylinder inflation problem, we stipulate
r = a :
σ r = −p i
r = b :
σ r = 0.
(4.103)
Solution The solution to this problem parallels that for the cylinder problem.
Substituting Eqs. (4.101) into (4.100) and solving for p yield
p(r) = ¯
σ r (r) +
b
r
( ¯
σ θ + ¯
σ φ − 2 ¯
σ r )
dr
r
,
(4.104)
which, since σ r = ¯
σ r − p, satisfies the second boundary condition in (4.103).
Applying the first boundary condition provides the cavity pressure
p i =
b
a
( ¯
σ θ + ¯
σ φ − 2 ¯
σ r )
dr
r
.
(4.105)
The numerical procedure follows that outlined in Sect. 4.4.
Membrane Approximation As the wall of a shell becomes thinner, its bending
stiffness decreases, and its behavior approaches that of a membrane except near
boundaries and concentrated loads. Because the difference between the inner and
outer radii decreases, the stretch ratios λ θ = λ φ = r/R and tangential stresses
σ θ = σ φ become relatively uniform across the wall. In the membrane theory of
shells, transmural variations in stress and strain are ignored (Libai and Simmonds
2005).
The membrane approximation can be obtained from the above equations by
assuming the stresses are uniform and r ≈ a ≈ b. Then, substituting Eqs. (4.101)
into (4.105) yields
p i ≈
h
a
(σ θ + σ φ − 2σ r ),
where h = b − a → 0 is the wall thickness of the deformed shell. Furthermore,
to satisfy the boundary conditions (4.103), the radial stress must vary across the
wall from −p i to 0, giving σ r = O(p i ). Thus, hσ r /a p i for a thin membrane
(h/a 1), and the above relation becomes
p i ≈
h
a
(σ θ + σ φ ).
(4.106)
Finally, symmetry gives the approximation
σ θ = σ φ =
p i a
2h
,
(4.107)