

material. As written, the integrals are from the surface to the
bottoming depth, with the factor of 2 accounting for the
return trip to the surface. If the source is not at the surface,
the limits of integration are changed appropriately.
For the flat geometry, we found it useful to describe the
travel time curve in terms of its slope, the ray parameter, p,
and the time axis intercept of its tangent, τ (Section 3.3.2). To
do the same for the spherical geometry, we write the travel time
curve as
T(p) = p∆(p) + τ(p).
(17)
We then evaluate the function
τ(p) = T(p) − p∆(p)
(18)
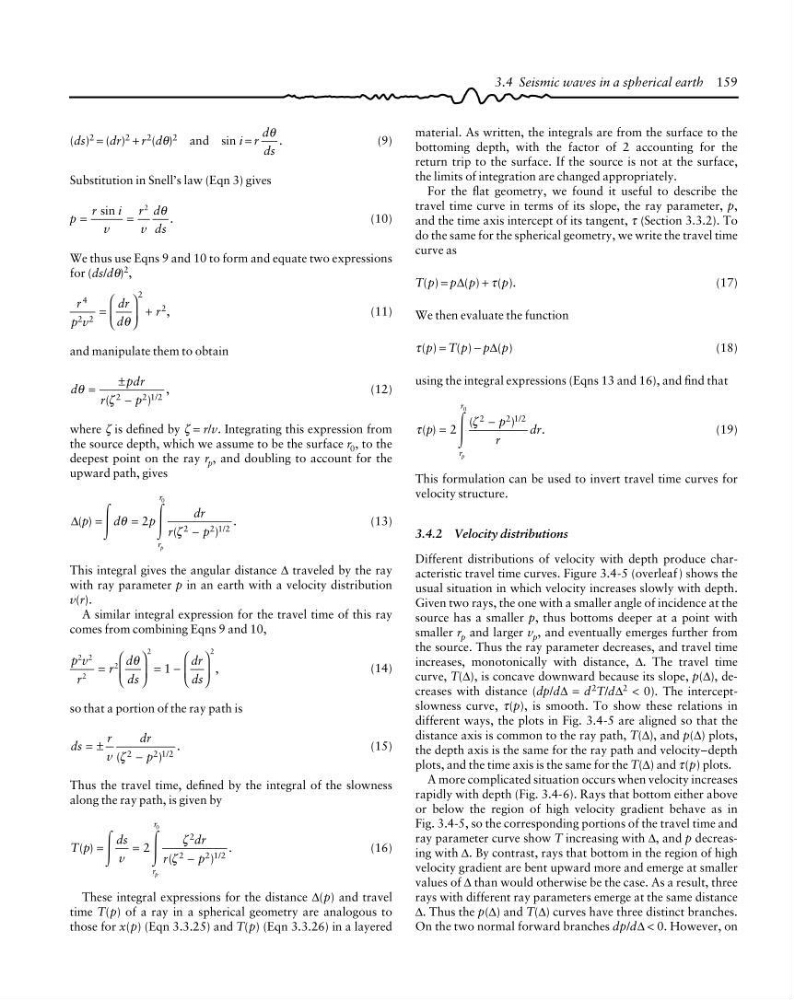
using the integral expressions (Eqns 13 and 16), and find that
τ
ζ
( )
(
)
.
/
p
p
r
dr
r
r
p
=
−
2
0
2
212
Ύ
(19)
This formulation can be used to invert travel time curves for
velocity structure.
3.4.2 Velocity distributions
Different distributions of velocity with depth produce characteristic travel time curves. Figure 3.4-5 (overleaf ) shows the
usual situation in which velocity increases slowly with depth.
Given two rays, the one with a smaller angle of incidence at the
source has a smaller p, thus bottoms deeper at a point with
smaller r p and larger v p , and eventually emerges further from
the source. Thus the ray parameter decreases, and travel time
increases, monotonically with distance, ∆. The travel time
curve, T(∆), is concave downward because its slope, p(∆), decreases with distance (dp/d∆ = d 2 T/d∆ 2 < 0). The interceptslowness curve, τ(p), is smooth. To show these relations in
different ways, the plots in Fig. 3.4-5 are aligned so that the
distance axis is common to the ray path, T(∆), and p(∆) plots,
the depth axis is the same for the ray path and velocity–depth
plots, and the time axis is the same for the T(∆) and τ(p) plots.
A more complicated situation occurs when velocity increases
rapidly with depth (Fig. 3.4-6). Rays that bottom either above
or below the region of high velocity gradient behave as in
Fig. 3.4-5, so the corresponding portions of the travel time and
ray parameter curve show T increasing with ∆, and p decreasing with ∆. By contrast, rays that bottom in the region of high
velocity gradient are bent upward more and emerge at smaller
values of ∆ than would otherwise be the case. As a result, three
rays with different ray parameters emerge at the same distance
∆. Thus the p(∆) and T(∆) curves have three distinct branches.
On the two normal forward branches dp/d∆ < 0. However, on
3.4 Seismic waves in a spherical earth 159
(ds) 2 = (dr) 2 + r 2 (dθ) 2 and sin i = r
d
ds
θ .
(9)
Substitution in Snell’s law (Eqn 3) gives
p
r
i
v
r
v
d
ds
sin
.
=
=
2
θ
(10)
We thus use Eqns 9 and 10 to form and equate two expressions
for (ds/dθ) 2 ,
r
p v
dr
d
r
4
2 2
2
2 ,
=
⎛
⎝
⎜
⎞
⎠
⎟ +
θ
(11)
and manipulate them to obtain
d
pdr
r
p
θ
ζ
(
)
,
/
=
±
−
2
212
(12)
where ζ is defined by ζ = r/v. Integrating this expression from
the source depth, which we assume to be the surface r 0 , to the
deepest point on the ray r p , and doubling to account for the
upward path, gives
∆( )
(
)
.
/
p
d
p
dr
r
p
r
r
p
=
=
−
Ύ Ύ
θ
ζ
2
0
2
212
(13)
This integral gives the angular distance ∆ traveled by the ray
with ray parameter p in an earth with a velocity distribution
v(r).
A similar integral expression for the travel time of this ray
comes from combining Eqns 9 and 10,
p v
r
r
d
ds
dr
ds
2 2
2
2
2
2
1
,
=
⎛
⎝
⎜
⎞
⎠
⎟ = −
⎛
⎝
⎜
⎞
⎠
⎟
θ
(14)
so that a portion of the ray path is
ds
r
v
dr
p
(
)
.
/
= ±
−
ζ 2
212
(15)
Thus the travel time, defined by the integral of the slowness
along the ray path, is given by
T p
ds
v
dr
r
p
r
r
p
( )
(
)
.
/
=
=
−
Ύ Ύ
2
0
2
2
212
ζ
ζ
(16)
These integral expressions for the distance ∆(p) and travel
time T(p) of a ray in a spherical geometry are analogous to
those for x(p) (Eqn 3.3.25) and T(p) (Eqn 3.3.26) in a layered