

The Periodic Transport
195
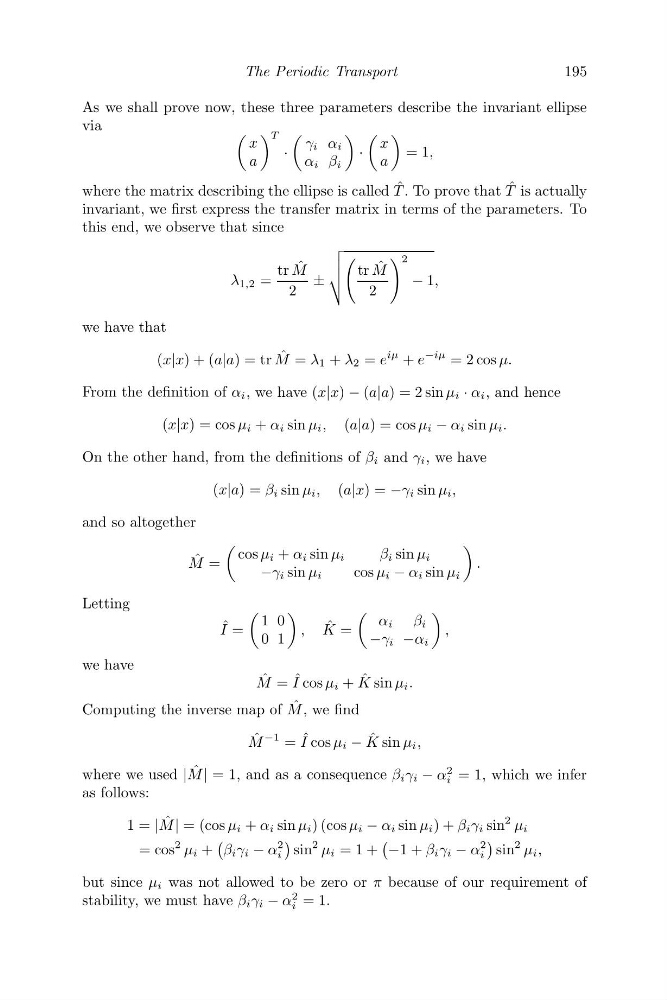
As we shall prove now, these three parameters describe the invariant ellipse
via
x
a
T
·
γ i α i
α i β i
·
x
a
= 1,
where the matrix describing the ellipse is called ˆ
T . To prove that ˆ
T is actually
invariant, we first express the transfer matrix in terms of the parameters. To
this end, we observe that since
λ 1,2 =
tr ˆ
M
2
±
tr ˆ
M
2
2
− 1,
we have that
(x|x) + (a|a) = tr ˆ
M = λ 1 + λ 2 = e
iμ + e
−iμ = 2 cos μ.
From the definition of α i , we have (x|x) − (a|a) = 2 sin μ i · α i , and hence
(x|x) = cos μ i + α i sin μ i , (a|a) = cos μ i − α i sin μ i .
On the other hand, from the definitions of β i and γ i , we have
(x|a) = β i sin μ i , (a|x) = −γ i sin μ i ,
and so altogether
ˆ
M =
cos μ i + α i sin μ i
β i sin μ i
−γ i sin μ i
cos μ i − α i sin μ i
.
Letting
ˆ
I =
1 0
0 1
, ˆ
K =
α i β i
−γ i −α i
,
we have
ˆ
M = ˆ
I cos μ i + ˆ
K sin μ i .
Computing the inverse map of ˆ
M , we find
ˆ
M
−1 = ˆ
I cos μ i − ˆ
K sin μ i ,
where we used | ˆ
M | = 1, and as a consequence β i γ i − α
2
i = 1, which we infer
as follows:
1 = | ˆ
M | = (cos μ i + α i sin μ i ) (cos μ i − α i sin μ i ) + β i γ i sin
2 μ i
= cos
2 μ i +
β i γ i − α
2
i
sin
2 μ i = 1 +
−1 + β i γ i − α
2
i
sin
2 μ i ,
but since μ i was not allowed to be zero or π because of our requirement of
stability, we must have β i γ i − α
2
i = 1.