

16 Application of Multi-agent Optimization Methods …
239
Table 16.2 Results of solving task 1
Optimization method
Coordinates of points
(x 1 (1), x 2 (1))
Switching coordinate
The value of the
functional I
Hybrid multi-agent
optimization method of
interpolation search
(0.444665, −0.13598) 0.5
−0.13598
Multi-agent optimization
algorithm using linear
regulators for agents
motion control
(0.44999, −0.13450)
0.5
−0.134550
Known solution [15]
(0.440804, −0.13593) 0.5
−0.13599
Table 16.3 Results of solving task 1
Optimization method
Coordinates of points
(x 1 (1), x 2 (1))
Coefficients in
expansion c i
The value of the
functional I
Hybrid multi-agent
optimization method of
interpolation search
(0.55055, −0.13349)
5.05, 6.51
−0.13598
Multi-agent optimization
algorithm using linear
regulators for agents
motion control
(0.57325, −0.13208)
4.63, 5.66
−0.13208
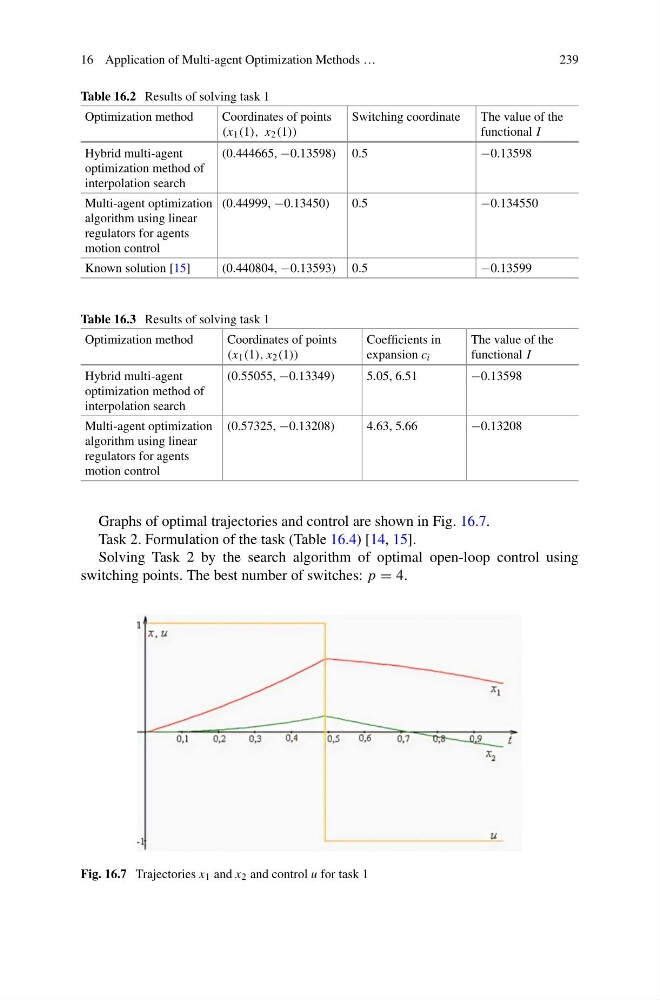
Graphs of optimal trajectories and control are shown in Fig. 16.7.
Task 2. Formulation of the task (Table 16.4) [14, 15].
Solving Task 2 by the search algorithm of optimal open-loop control using
switching points. The best number of switches: p = 4.
Fig. 16.7 Trajectories x 1 and x 2 and control u for task 1