

238
A. V. Panteleev and M. M. S. Karane
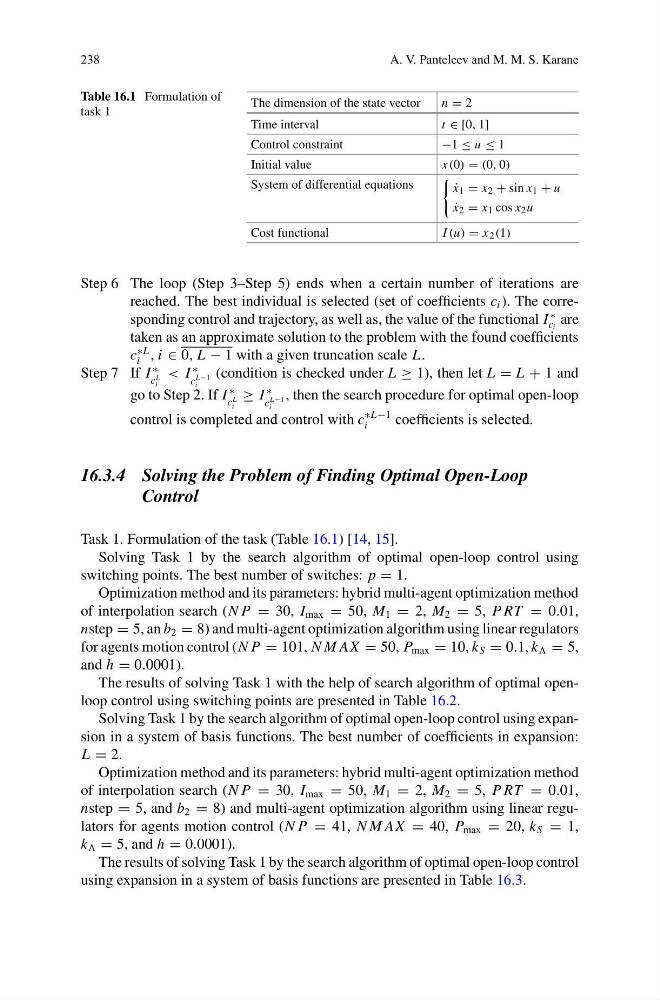
Table 16.1 Formulation of
task 1
The dimension of the state vector
n = 2
Time interval
t ∈ [0, 1]
Control constraint
−1 ≤ u ≤ 1
Initial value
x(0) = (0, 0)
System of differential equations
˙
x 1 = x 2 + sin x 1 + u
˙
x 2 = x 1 cos x 2 u
Cost functional
I (u) = x 2 (1)
Step 6 The loop (Step 3–Step 5) ends when a certain number of iterations are
reached. The best individual is selected (set of coefficients c i ). The corresponding control and trajectory, as well as, the value of the functional I
∗
c i
are
taken as an approximate solution to the problem with the found coefficients
c
∗L
i , i ∈ 0, L − 1 with a given truncation scale L.
Step 7 If I
∗
c
L
i
< I
∗
c
L−1
i
(condition is checked under L ≥ 1), then let L = L + 1 and
go to Step 2. If I
∗
c
L
i
≥ I
∗
c
L−1
i
, then the search procedure for optimal open-loop
control is completed and control with c
∗L−1
i
coefficients is selected.
16.3.4 Solving the Problem of Finding Optimal Open-Loop
Control
Task 1. Formulation of the task (Table 16.1) [14, 15].
Solving Task 1 by the search algorithm of optimal open-loop control using
switching points. The best number of switches: p = 1.
Optimization method and its parameters: hybrid multi-agent optimization method
of interpolation search (N P = 30, I max = 50, M 1 = 2, M 2 = 5, P RT = 0.01,
nstep = 5, an b 2 = 8) and multi-agent optimization algorithm using linear regulators
for agents motion control (N P = 101, N M AX = 50, P max = 10, k S = 0.1, k = 5,
and h = 0.0001).
The results of solving Task 1 with the help of search algorithm of optimal openloop control using switching points are presented in Table 16.2.
Solving Task 1 by the search algorithm of optimal open-loop control using expansion in a system of basis functions. The best number of coefficients in expansion:
L = 2.
Optimization method and its parameters: hybrid multi-agent optimization method
of interpolation search (N P = 30, I max = 50, M 1 = 2, M 2 = 5, P RT = 0.01,
nstep = 5, and b 2 = 8) and multi-agent optimization algorithm using linear regulators for agents motion control (N P = 41, N M AX = 40, P max = 20, k S = 1,
k = 5, and h = 0.0001).
The results of solving Task 1 by the search algorithm of optimal open-loop control
using expansion in a system of basis functions are presented in Table 16.3.