

16 Application of Multi-agent Optimization Methods …
229
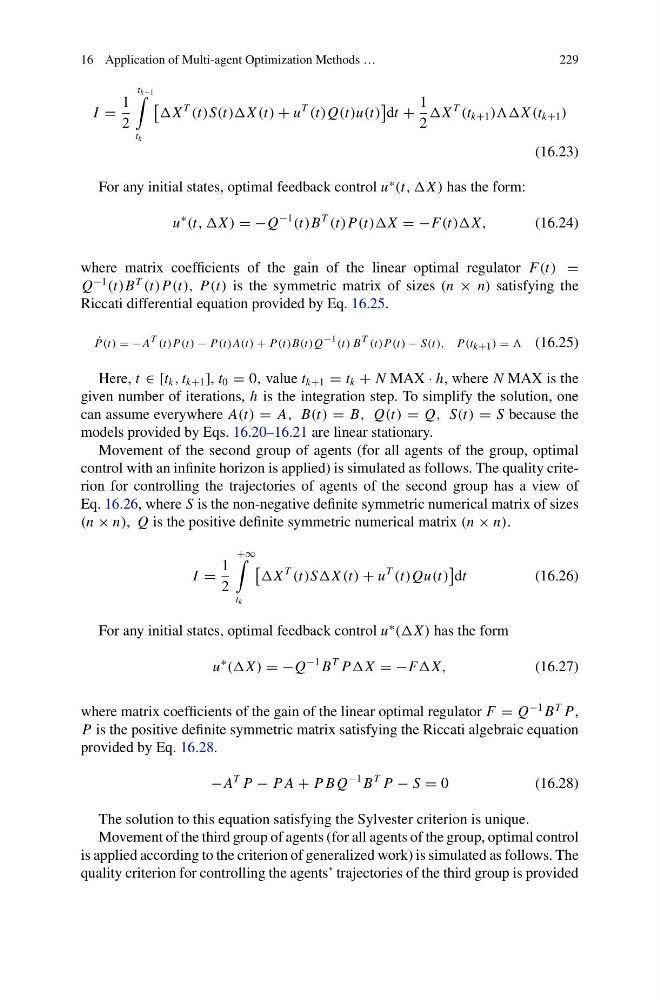
I =
1
2
t k+1
t k
X
T
(t)S(t))X (t) + u
T
(t)Q(t)u(t)
dt +
1
2
X
T
(t k+1 )))X (t k+1 )
(16.23)
For any initial states, optimal feedback control u
∗
(t, ,X ) has the form:
u
∗
(t, ,X ) = −Q
−1
(t)B
T
(t)P(t))X = −F(t))X,
(16.24)
where matrix coefficients of the gain of the linear optimal regulator F(t) =
Q
−1
(t)B
T
(t)P(t), P(t) is the symmetric matrix of sizes (n × n) satisfying the
Riccati differential equation provided by Eq. 16.25.
˙
P(t) = −A T (t)P(t) − P(t)A(t) + P(t)B(t)Q −1 (t) B T (t)P(t) − S(t), P(t k+1 ) = (16.25)
Here, t ∈ [t k , t k+1 ], t 0 = 0, value t k+1 = t k + N MAX · h, where N MAX is the
given number of iterations, h is the integration step. To simplify the solution, one
can assume everywhere A(t) = A, B(t) = B, Q(t) = Q, S(t) = S because the
models provided by Eqs. 16.20–16.21 are linear stationary.
Movement of the second group of agents (for all agents of the group, optimal
control with an infinite horizon is applied) is simulated as follows. The quality criterion for controlling the trajectories of agents of the second group has a view of
Eq. 16.26, where S is the non-negative definite symmetric numerical matrix of sizes
(n × n), Q is the positive definite symmetric numerical matrix (n × n).
I =
1
2
+∞
t k
X
T
(t)SX (t) + u
T
(t)Qu(t)
dt
(16.26)
For any initial states, optimal feedback control u
∗
((X ) has the form
u
∗
((X ) = −Q
−1 B
T PX = −FX,
(16.27)
where matrix coefficients of the gain of the linear optimal regulator F = Q
−1 B
T P,
P is the positive definite symmetric matrix satisfying the Riccati algebraic equation
provided by Eq. 16.28.
−A
T P − P A + P B Q
−1 B
T P − S = 0
(16.28)
The solution to this equation satisfying the Sylvester criterion is unique.
Movement of the third group of agents (for all agents of the group, optimal control
is applied according to the criterion of generalized work) is simulated as follows. The
quality criterion for controlling the agents’ trajectories of the third group is provided