

also come from some internal oscillator degree of freedom, corresponding to a
system model autonomous in Xt. The MDSM can be extended to analyzing this
case, as demonstrated by Sheheitli and Rand (2011, 2012) for a system model with
three coupled van der Pol oscillators having vastly different frequencies, and a
mass-spring-pendulum system with vastly different frequencies.
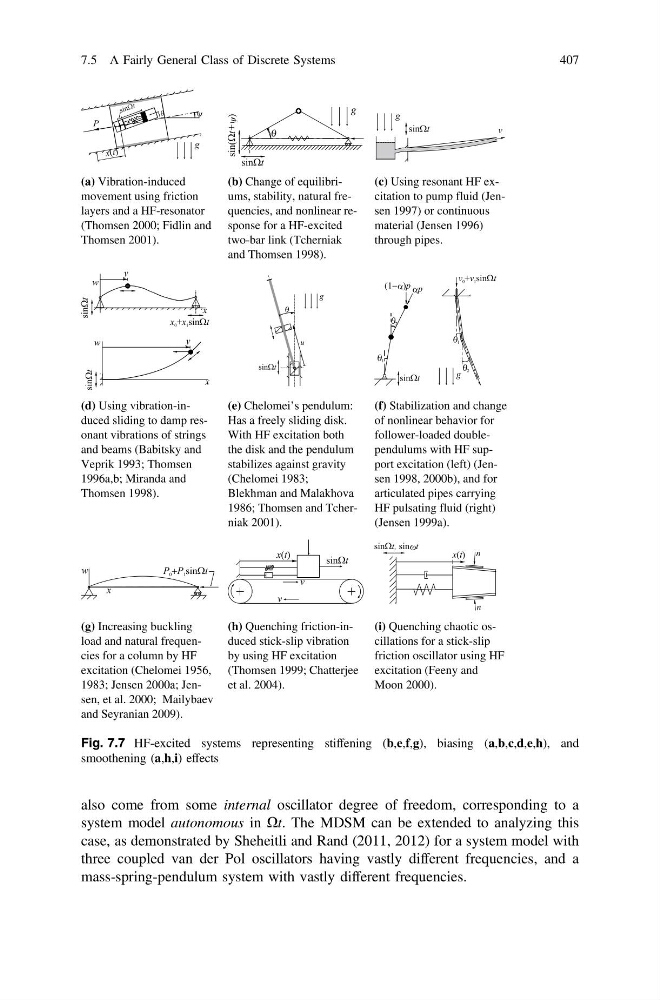
Fig. 7.7 HF-excited systems representing stiffening (b,e,f,g), biasing (a,b,c,d,e,h), and
smoothening (a,h,i) effects
7.5 A Fairly General Class of Discrete Systems
407