

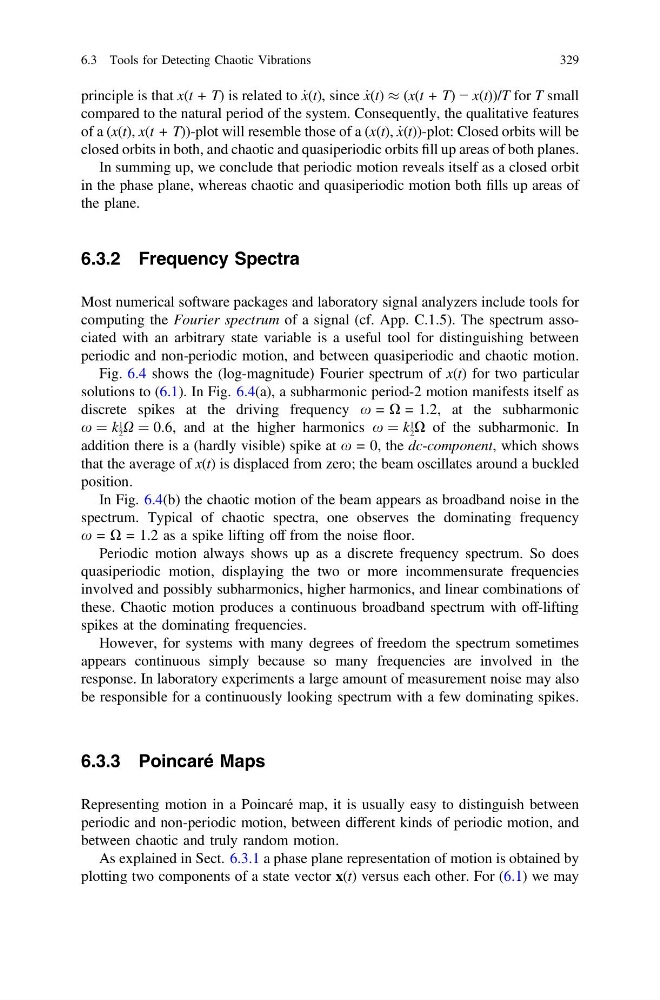
principle is that x(t + T) is related to _
x(t), since _
x(t) % (x(t + T) − x(t))/T for T small
compared to the natural period of the system. Consequently, the qualitative features
of a (x(t), x(t + T))-plot will resemble those of a (x(t), _
x(t))-plot: Closed orbits will be
closed orbits in both, and chaotic and quasiperiodic orbits fill up areas of both planes.
In summing up, we conclude that periodic motion reveals itself as a closed orbit
in the phase plane, whereas chaotic and quasiperiodic motion both fills up areas of
the plane.
6.3.2 Frequency Spectra
Most numerical software packages and laboratory signal analyzers include tools for
computing the Fourier spectrum of a signal (cf. App. C.1.5). The spectrum associated with an arbitrary state variable is a useful tool for distinguishing between
periodic and non-periodic motion, and between quasiperiodic and chaotic motion.
Fig. 6.4 shows the (log-magnitude) Fourier spectrum of x(t) for two particular
solutions to (6.1). In Fig. 6.4(a), a subharmonic period-2 motion manifests itself as
discrete spikes at the driving frequency x = X = 1.2, at the subharmonic
x ¼ k
1
2 X ¼ 0.6, and at the higher harmonics x ¼ k
1
2 X of the subharmonic. In
addition there is a (hardly visible) spike at x = 0, the dc-component, which shows
that the average of x(t) is displaced from zero; the beam oscillates around a buckled
position.
In Fig. 6.4(b) the chaotic motion of the beam appears as broadband noise in the
spectrum. Typical of chaotic spectra, one observes the dominating frequency
x = X = 1.2 as a spike lifting off from the noise floor.
Periodic motion always shows up as a discrete frequency spectrum. So does
quasiperiodic motion, displaying the two or more incommensurate frequencies
involved and possibly subharmonics, higher harmonics, and linear combinations of
these. Chaotic motion produces a continuous broadband spectrum with off-lifting
spikes at the dominating frequencies.
However, for systems with many degrees of freedom the spectrum sometimes
appears continuous simply because so many frequencies are involved in the
response. In laboratory experiments a large amount of measurement noise may also
be responsible for a continuously looking spectrum with a few dominating spikes.
6.3.3 Poincaré Maps
Representing motion in a Poincaré map, it is usually easy to distinguish between
periodic and non-periodic motion, between different kinds of periodic motion, and
between chaotic and truly random motion.
As explained in Sect. 6.3.1 a phase plane representation of motion is obtained by
plotting two components of a state vector x(t) versus each other. For (6.1) we may
6.3 Tools for Detecting Chaotic Vibrations
329