

where b j denote the modal damping factors.
Problem 3.3 For each of the systems below, determine the singular points,
determine their type and stability, and sketch the phase plane orbits near the singular points when 0 < b < 1.
a) ü + 2b _
u + u + u
3 = 0
b) ü + 2b _
u + u – u
3 = 0
c) ü + 2b _
u – u + u
3 = 0
d) ü + 2b _
u – u – u
3 = 0
Problem 3.4 Consider the equation of motion for a pendulum with a constant
torque M at the supporting hinge:
€ h þ 2b _
h þ x
2 sin h ¼ M:
ð3:320Þ
Letting x 1 = h and x 2 = _
h, determine the singular points in the (x 1 , x 2 ) phase
plane. Discuss the character of nonlinear motions near the singular points.
Problem 3.5 Consider the equation of motion governing arbitrarily large oscillations of a pendulum with quadratic damping:
€ h þ 2b _
hj _
hj þ x
2 sin h ¼ 0:
ð3:321Þ
Letting x 1 = h and x 2 = _
h, determine the singular points in the (x 1 , x 2 ) phase
plane. Discuss the character of nonlinear motions near the singular points and
sketch the corresponding phase plane orbits.
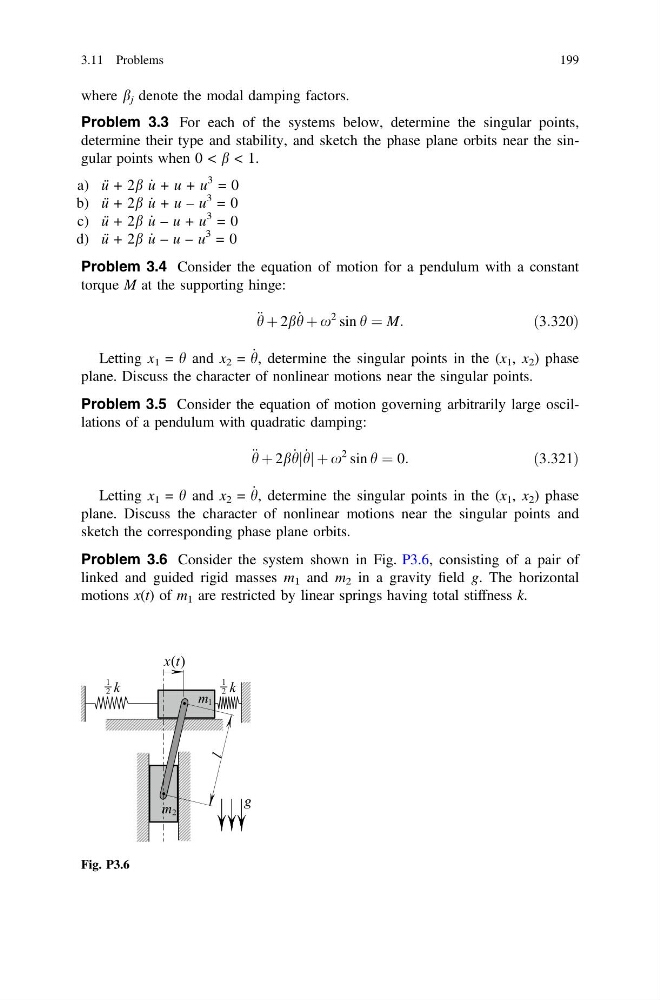
Problem 3.6 Consider the system shown in Fig. P3.6, consisting of a pair of
linked and guided rigid masses m 1 and m 2 in a gravity field g. The horizontal
motions x(t) of m 1 are restricted by linear springs having total stiffness k.
Fig. P3.6
3.11 Problems
199