

linear damping parameter ^
b can be also negative (if h 1 is sufficiently negative, cf.
the definition of h 1 below (3.283)). In that case energy from the running belt is
transferred to the mass and the spring, leading to self-excited oscillations, that may
be stabilized by nonlinearities such as the h 3 -term.
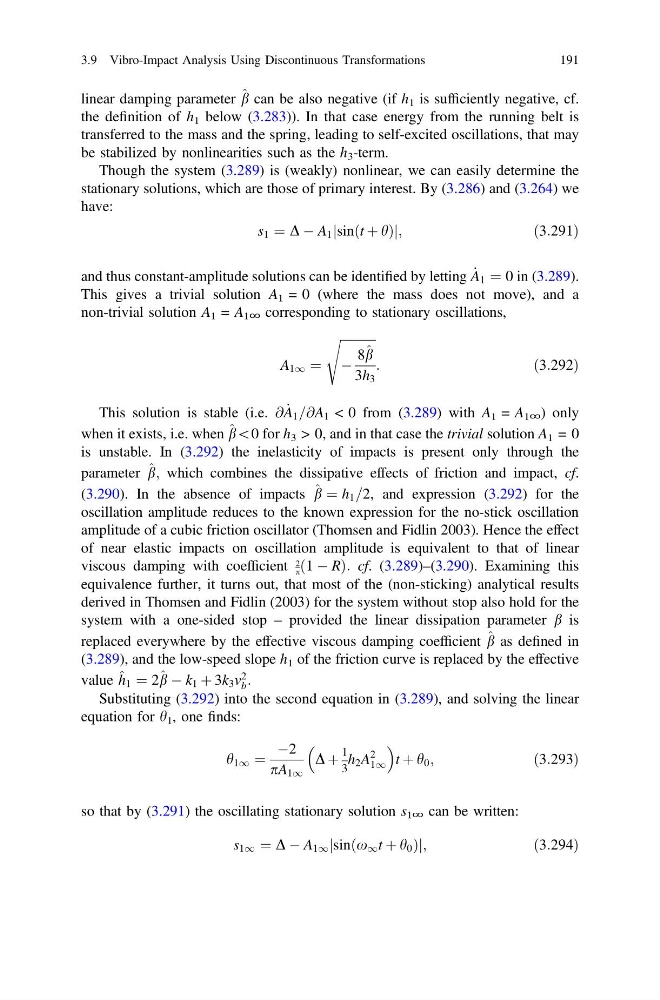
Though the system (3.289) is (weakly) nonlinear, we can easily determine the
stationary solutions, which are those of primary interest. By (3.286) and (3.264) we
have:
s 1 ¼ D À A 1 sinðt þ hÞ
j
j ;
ð3:291Þ
and thus constant-amplitude solutions can be identified by letting _
A 1 ¼ 0 in (3.289).
This gives a trivial solution A 1 = 0 (where the mass does not move), and a
non-trivial solution A 1 = A 1∞ corresponding to stationary oscillations,
A 11 ¼
ffiffiffiffiffiffiffiffiffiffiffi ffi
À
8 ^
b
3h 3
s
:
ð3:292Þ
This solution is stable (i.e. @ _
A 1 =@A 1 < 0 from (3.289) with A 1 = A 1∞ ) only
when it exists, i.e. when ^
b\0 for h 3 > 0, and in that case the trivial solution A 1 = 0
is unstable. In (3.292) the inelasticity of impacts is present only through the
parameter ^
b; which combines the dissipative effects of friction and impact, cf.
(3.290). In the absence of impacts ^
b ¼ h 1 =2, and expression (3.292) for the
oscillation amplitude reduces to the known expression for the no-stick oscillation
amplitude of a cubic friction oscillator (Thomsen and Fidlin 2003). Hence the effect
of near elastic impacts on oscillation amplitude is equivalent to that of linear
viscous damping with coefficient
2
p ð1 À RÞ: cf. (3.289)–(3.290). Examining this
equivalence further, it turns out, that most of the (non-sticking) analytical results
derived in Thomsen and Fidlin (2003) for the system without stop also hold for the
system with a one-sided stop – provided the linear dissipation parameter b is
replaced everywhere by the effective viscous damping coefficient ^
b as defined in
(3.289), and the low-speed slope h 1 of the friction curve is replaced by the effective
value ^ h 1 ¼ 2 ^
b À k 1 þ 3k 3 v
2
b :
Substituting (3.292) into the second equation in (3.289), and solving the linear
equation for h 1 , one finds:
h 11 ¼
À2
pA 11
D þ
1
3
h 2 A
2
11
t þ h 0 ;
ð3:293Þ
so that by (3.291) the oscillating stationary solution s 1∞ can be written:
s 11 ¼ D À A 11 sin x 1 t þ h 0
ð
Þ
j
j ;
ð3:294Þ
3.9 Vibro-Impact Analysis Using Discontinuous Transformations
191