

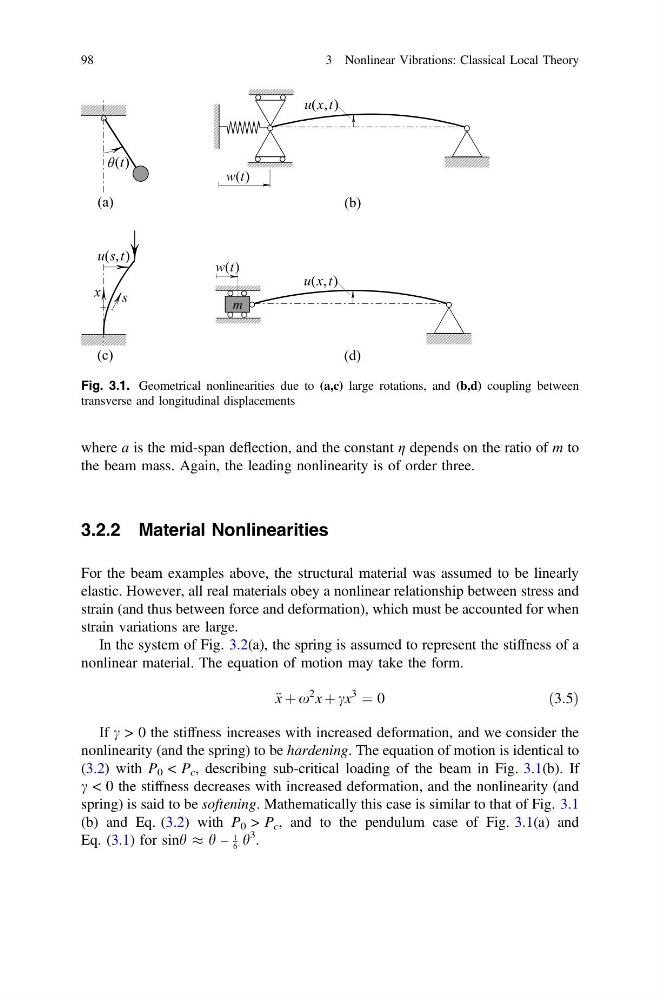
where a is the mid-span deflection, and the constant η depends on the ratio of m to
the beam mass. Again, the leading nonlinearity is of order three.
3.2.2 Material Nonlinearities
For the beam examples above, the structural material was assumed to be linearly
elastic. However, all real materials obey a nonlinear relationship between stress and
strain (and thus between force and deformation), which must be accounted for when
strain variations are large.
In the system of Fig. 3.2(a), the spring is assumed to represent the stiffness of a
nonlinear material. The equation of motion may take the form.
€ x þ x
2 x þ cx
3
¼ 0
ð3:5Þ
If c > 0 the stiffness increases with increased deformation, and we consider the
nonlinearity (and the spring) to be hardening. The equation of motion is identical to
(3.2) with P 0 < P c , describing sub-critical loading of the beam in Fig. 3.1(b). If
c < 0 the stiffness decreases with increased deformation, and the nonlinearity (and
spring) is said to be softening. Mathematically this case is similar to that of Fig. 3.1
(b) and Eq. (3.2) with P 0 > P c , and to the pendulum case of Fig. 3.1(a) and
Eq. (3.1) for sinh % h –
1
6 h
3 .
Fig. 3.1. Geometrical nonlinearities due to (a,c) large rotations, and (b,d) coupling between
transverse and longitudinal displacements
98
3 Nonlinear Vibrations: Classical Local Theory