

44
3 Geometrically Nonlinear Theories
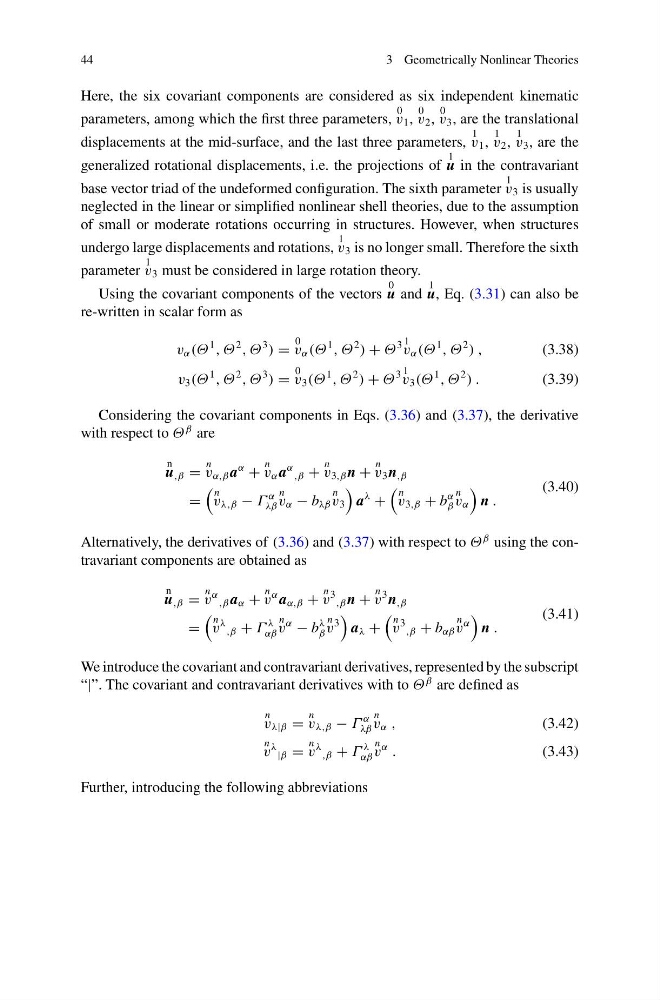
Here, the six covariant components are considered as six independent kinematic
parameters, among which the first three parameters,
0
v 1 ,
0
v 2 ,
0
v 3 , are the translational
displacements at the mid-surface, and the last three parameters,
1
v 1 ,
1
v 2 ,
1
v 3 , are the
generalized rotational displacements, i.e. the projections of
1
u in the contravariant
base vector triad of the undeformed configuration. The sixth parameter
1
v 3 is usually
neglected in the linear or simplified nonlinear shell theories, due to the assumption
of small or moderate rotations occurring in structures. However, when structures
undergo large displacements and rotations,
1
v 3 is no longer small. Therefore the sixth
parameter
1
v 3 must be considered in large rotation theory.
Using the covariant components of the vectors
0
u and
1
u, Eq. (3.31) can also be
re-written in scalar form as
v α (Θ
1
, Θ
2
, Θ
3
) =
0
v α (Θ
1
, Θ
2
) + Θ
3 1
v α (Θ
1
, Θ
2
) ,
(3.38)
v 3 (Θ
1
, Θ
2
, Θ
3
) =
0
v 3 (Θ
1
, Θ
2
) + Θ
3 1
v 3 (Θ
1
, Θ
2
) .
(3.39)
Considering the covariant components in Eqs. (3.36) and (3.37), the derivative
with respect to Θ
β are
n
u ,β =
n
v α,β a
α
+
n
v α a
α ,β +
n
v 3,β n +
n
v 3 n ,β
=
n
v λ,β − Γ
α
λβ
n
v α − b λβ
n
v 3
a
λ
+
n
v 3,β + b
α
β
n
v α
n .
(3.40)
Alternatively, the derivatives of (3.36) and (3.37) with respect to Θ
β using the contravariant components are obtained as
n
u ,β =
n
v
α ,β a α +
n
v
α a α,β +
n
v
3 ,β n +
n
v
3 n ,β
=
n
v
λ ,β + Γ
λ
αβ
n
v
α
− b
λ
β
n
v
3
a λ +
n
v
3 ,β + b αβ
n
v
α
n .
(3.41)
We introduce the covariant and contravariant derivatives, represented by the subscript
“|”. The covariant and contravariant derivatives with to Θ
β are defined as
n
v λ|β =
n
v λ,β − Γ
α
λβ
n
v α ,
(3.42)
n
v
λ |β =
n
v
λ ,β + Γ
λ
αβ
n
v
α
.
(3.43)
Further, introducing the following abbreviations