

e
P
{ ¼ e
P
T ¼ e
P
À1
ð17:110Þ
and
e
PU ¼
cos α cos β À sin α cos α sin β
sin α cos β
cos α
sin α sin β
À sin β
0
cos β
0
B
B
@
1
C
C
A
1
ffiffi ffi
2
p
1
ffiffi ffi
2
p
0
À
i ffiffi ffi
2
p
i ffiffi ffi
2
p
0
0
0 1
0
B
B
B
B
B
@
1
C
C
C
C
C
A
¼
1
ffiffi ffi
2
p cos α cos β þ
i ffiffi ffi
2
p sin α
1
ffiffi ffi
2
p cos α cos β À
i ffiffi ffi
2
p sin α cos α sin β
1
ffiffi ffi
2
p sin α cos β À
i ffiffi ffi
2
p cos α
1
ffiffi ffi
2
p sin α cos β þ
i ffiffi ffi
2
p cos α sin α sin β
À
1
ffiffi ffi
2
p sin β
À
1
ffiffi ffi
2
p sin β
cos β
0
B
B
B
B
B
B
B
@
1
C
C
C
C
C
C
C
A
:
ð17:111Þ
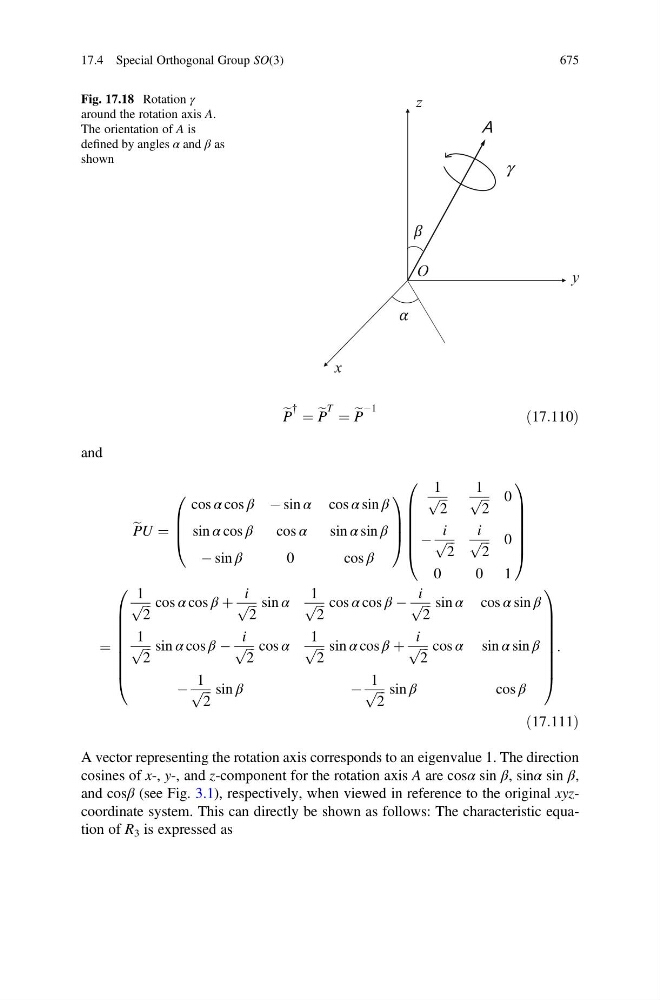
A vector representing the rotation axis corresponds to an eigenvalue 1. The direction
cosines of x-, y-, and z-component for the rotation axis A are cosα sin β, sinα sin β,
and cosβ (see Fig. 3.1), respectively, when viewed in reference to the original xyzcoordinate system. This can directly be shown as follows: The characteristic equation of R 3 is expressed as
y
x
z
O
γ
$
Fig. 17.18 Rotation γ
around the rotation axis A.
The orientation of A is
defined by angles α and β as
shown
17.4 Special Orthogonal Group SO(3)
675
P
{ ¼ e
P
T ¼ e
P
À1
ð17:110Þ
and
e
PU ¼
cos α cos β À sin α cos α sin β
sin α cos β
cos α
sin α sin β
À sin β
0
cos β
0
B
B
@
1
C
C
A
1
ffiffi ffi
2
p
1
ffiffi ffi
2
p
0
À
i ffiffi ffi
2
p
i ffiffi ffi
2
p
0
0
0 1
0
B
B
B
B
B
@
1
C
C
C
C
C
A
¼
1
ffiffi ffi
2
p cos α cos β þ
i ffiffi ffi
2
p sin α
1
ffiffi ffi
2
p cos α cos β À
i ffiffi ffi
2
p sin α cos α sin β
1
ffiffi ffi
2
p sin α cos β À
i ffiffi ffi
2
p cos α
1
ffiffi ffi
2
p sin α cos β þ
i ffiffi ffi
2
p cos α sin α sin β
À
1
ffiffi ffi
2
p sin β
À
1
ffiffi ffi
2
p sin β
cos β
0
B
B
B
B
B
B
B
@
1
C
C
C
C
C
C
C
A
:
ð17:111Þ
A vector representing the rotation axis corresponds to an eigenvalue 1. The direction
cosines of x-, y-, and z-component for the rotation axis A are cosα sin β, sinα sin β,
and cosβ (see Fig. 3.1), respectively, when viewed in reference to the original xyzcoordinate system. This can directly be shown as follows: The characteristic equation of R 3 is expressed as
y
x
z
O
γ
$
Fig. 17.18 Rotation γ
around the rotation axis A.
The orientation of A is
defined by angles α and β as
shown
17.4 Special Orthogonal Group SO(3)
675