

e σ ¼
cos θ À sin θ 0
sin θ
cos θ 0
0
0
1
0
B
B
@
1
C
C
A
1 0 0
0 À1 0
0 0 1
0
B
B
@
1
C
C
A
cos θ
sin θ 0
À sin θ cos θ 0
0
0
1
0
B
B
@
1
C
C
A
¼
cos 2θ
sin 2θ 0
sin 2θ À cos 2θ 0
0
0
1
0
B
B
@
1
C
C
A :
ð17:20Þ
Notice that this matrix representation is referred to the original xyz-coordinate
system; see discussion of Sect. 11.4. Hence, we describe the successive transformations σ followed by e σ as
y
x
z
O
θ
(a)
2
(b)
(c)
‒2
$
$
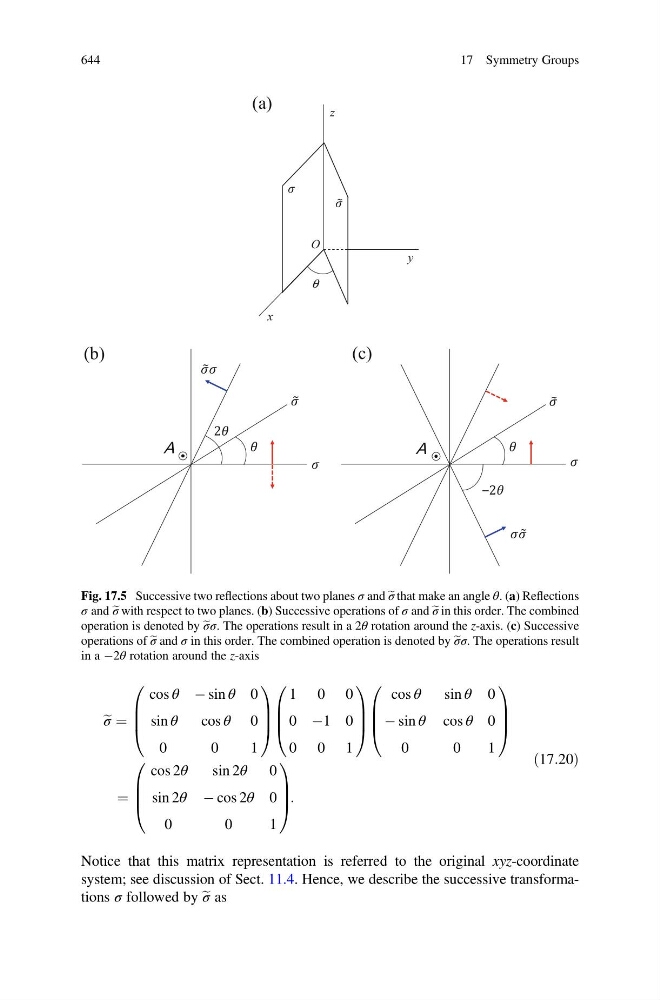
Fig. 17.5 Successive two reflections about two planes σ and e σ that make an angle θ. (a) Reflections
σ and e σ with respect to two planes. (b) Successive operations of σ and e σ in this order. The combined
operation is denoted by e σσ. The operations result in a 2θ rotation around the z-axis. (c) Successive
operations of e σ and σ in this order. The combined operation is denoted by e σσ. The operations result
in a À2θ rotation around the z-axis
644
17 Symmetry Groups