

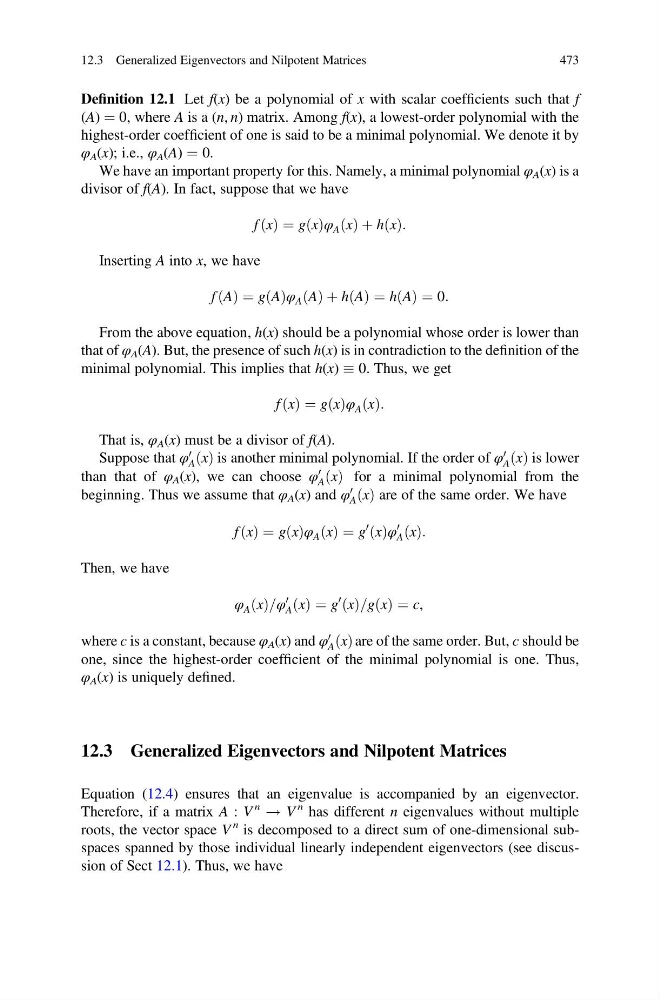
Definition 12.1 Let f(x) be a polynomial of x with scalar coefficients such that f
(A) ¼ 0, where A is a (n, n) matrix. Among f(x), a lowest-order polynomial with the
highest-order coefficient of one is said to be a minimal polynomial. We denote it by
φ A (x); i.e., φ A (A) ¼ 0.
We have an important property for this. Namely, a minimal polynomial φ A (x) is a
divisor of f(A). In fact, suppose that we have
f x
ð Þ ¼ g x
ð Þφ A x
ð Þ þ h x
ð Þ:
Inserting A into x, we have
f A
ð Þ ¼ g A
ð Þφ A A
ð Þ þ h A
ð Þ ¼ h A
ð Þ ¼ 0:
From the above equation, h(x) should be a polynomial whose order is lower than
that of φ A (A). But, the presence of such h(x) is in contradiction to the definition of the
minimal polynomial. This implies that h(x) 0. Thus, we get
f x
ð Þ ¼ g x
ð Þφ A x
ð Þ:
That is, φ A (x) must be a divisor of f(A).
Suppose that φ
0
A x
ð Þ is another minimal polynomial. If the order of φ
0
A x
ð Þ is lower
than that of φ A (x), we can choose φ
0
A x
ð Þ for a minimal polynomial from the
beginning. Thus we assume that φ A (x) and φ
0
A x
ð Þ are of the same order. We have
f x
ð Þ ¼ g x
ð Þφ A x
ð Þ ¼ g
0 x
ð Þφ
0
A x
ð Þ:
Then, we have
φ A x
ð Þ=φ
0
A x
ð Þ ¼ g
0 x
ð Þ=g x
ð Þ ¼ c,
where c is a constant, because φ A (x) and φ
0
A x
ð Þare of the same order. But, c should be
one, since the highest-order coefficient of the minimal polynomial is one. Thus,
φ A (x) is uniquely defined.
12.3 Generalized Eigenvectors and Nilpotent Matrices
Equation (12.4) ensures that an eigenvalue is accompanied by an eigenvector.
Therefore, if a matrix A : V
n
! V
n has different n eigenvalues without multiple
roots, the vector space V
n is decomposed to a direct sum of one-dimensional subspaces spanned by those individual linearly independent eigenvectors (see discussion of Sect 12.1). Thus, we have
12.3 Generalized Eigenvectors and Nilpotent Matrices
473