

Kinematic and Kinetic Analysis of a Biomechanical Model
59
The series elastic stiffness is defined based on Wilkie’s work [15, 16]. When the force
is equal to the maximum isometric force, the deflection will be the shortening length of
the tendon:
K se =
P o
I o ·
1 −
L f
L m
· f m
,
where f m is the maximum deflection ratio. We chose the value of 4 percent here, as used
in Winter’s study of Hill-based muscle modeling [17] and the Meijer study of rat medial
gastrocnemius muscle [18].
The parallel elastic stiffness is calculated based on the observation that under max
load at steady state, the series and parallel elastic components absorb all the force:
K PE =
K SE · P 0
K SE ·
I o /
L f
L m
· f m − P 0
2.4 Inverse Kinematic Analysis
When developing a synthetic neural controller, it is necessary to calculate the desired
motoneuron activations [2]. To do this, an inverse kinematic and kinetic analysis was
developed to determine muscle attachments points, and therefore the muscle lengths,
velocities and forces that lead to desired movements. Inverse kinematics also enables us
to convert external forces acting on the feet into joint torques, via the Jacobian.
The analysis is done in Matlab, where the Animatlab model is loaded in and a leg
object is automatically constructed [2]. We utilized experimental rat joint profiles from
previous work [1] and the following rotational transformation matrix to reproduce rat
hind limb walking and track limb segment positions:
P(i) = P(i − 1) + C(i − 1) · P b (i) + C(i − 1) · [I − c(i)] · R(i) · P j (i)
where P(i) is the i th limb segment center of mass position during walking, P(1) is
the position of the pelvis, which is [0,0,0]; P b (i) is the ith limb segment center of mass
position relative to the proximal segment of the ith segment; P j (i) is the ith joint position
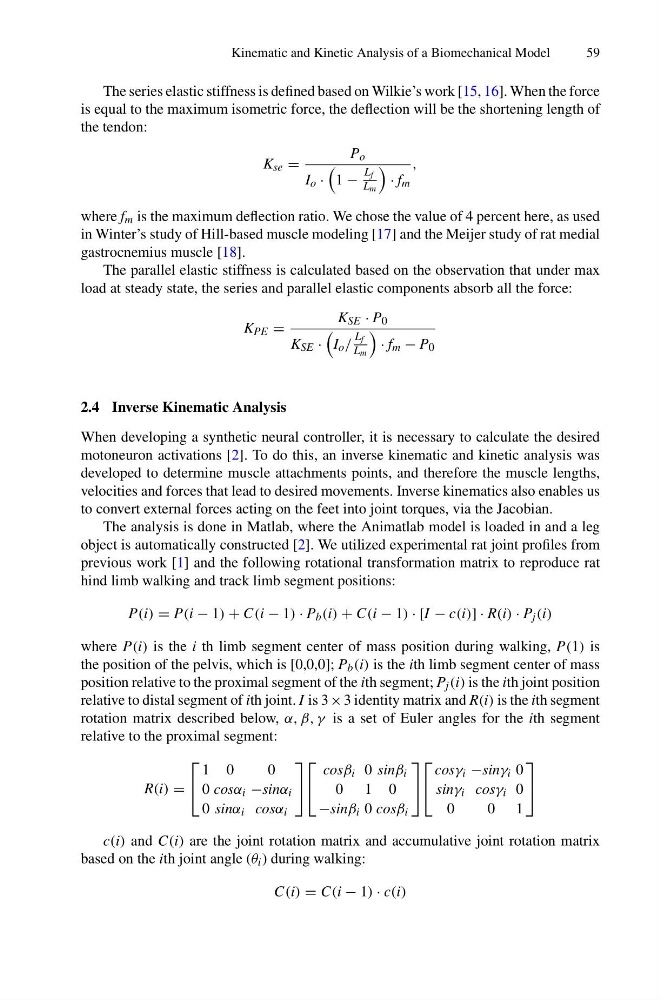
relative to distal segment of ith joint. I is 3 × 3 identity matrix and R(i) is the ith segment
rotation matrix described below, α, β, γ is a set of Euler angles for the ith segment
relative to the proximal segment:
R(i) =
⎡
⎣
1 0
0
0 cosα i −sinα i
0 sinα i cosα i
⎤
⎦
⎡
⎣
cosβ i 0 sinβ i
0 1 0
−sinβ i 0 cosβ i
⎤
⎦
⎡
⎣
cosγ i −sinγ i 0
sinγ i cosγ i 0
0
0 1
⎤
⎦
c(i) and C(i) are the joint rotation matrix and accumulative joint rotation matrix
based on the ith joint angle (θ i ) during walking:
C(i) = C(i − 1) · c(i)