

32
I. Chatzikonstantinou et al.
5 Discussion
Looking at the validation results and with respect to resource allocation and
topology, we observed the following:
– We are able to obtain sane resource assignment for teams of human and robot
workers that maximizes
– The allocation algorithm “augments” the processing capacity for those device
types that are mostly in demand with the aim of reducing the lag in overall
device processing capability.
– The augmentation occurs through 1. allocation of additional workstations
for the particular device type and 2. allocation of more capable agents to
accelerate device processing.
– Human workers are resources that are necessary to perform some disassembly
steps. In order to maximize efficiency, the proposed method often resolves to
sharing of those resources among more than one workstations. In this sense,
even though robots are usually slower in processing than humans, they are
allocated to perform tasks in parallel, with humans only intervening for tasks
that are absolutely necessary, thus achieving speedup.
– From a topological perspective, the proposed approach generates allocates
workstations that minimize the overall transport time, taking into account
the fact that the speed of different agents is not the same.
– The above behaviors of the system are emergent and occur as a result of the
optimization process.
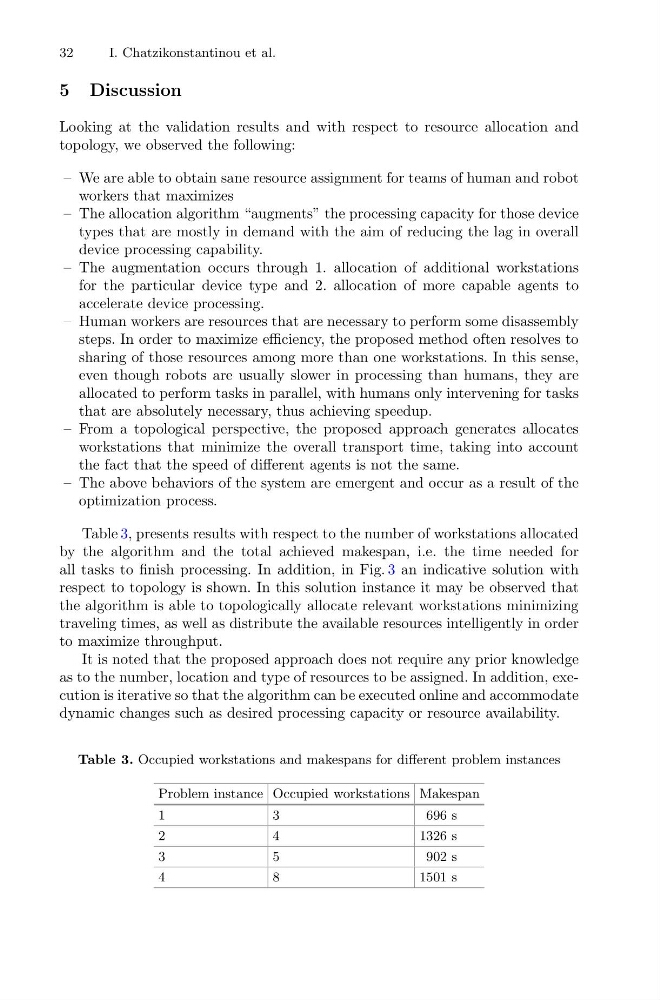
Table 3, presents results with respect to the number of workstations allocated
by the algorithm and the total achieved makespan, i.e. the time needed for
all tasks to finish processing. In addition, in Fig. 3 an indicative solution with
respect to topology is shown. In this solution instance it may be observed that
the algorithm is able to topologically allocate relevant workstations minimizing
traveling times, as well as distribute the available resources intelligently in order
to maximize throughput.
It is noted that the proposed approach does not require any prior knowledge
as to the number, location and type of resources to be assigned. In addition, execution is iterative so that the algorithm can be executed online and accommodate
dynamic changes such as desired processing capacity or resource availability.
Table 3. Occupied workstations and makespans for different problem instances
Problem instance Occupied workstations Makespan
1
3
696 s
2
4
1326 s
3
5
902 s
4
8
1501 s