

The Central Complex Path Integration Circuit Deployed on an MAV
331
sensor. The trial is terminated when the memory cell range estimate falls below
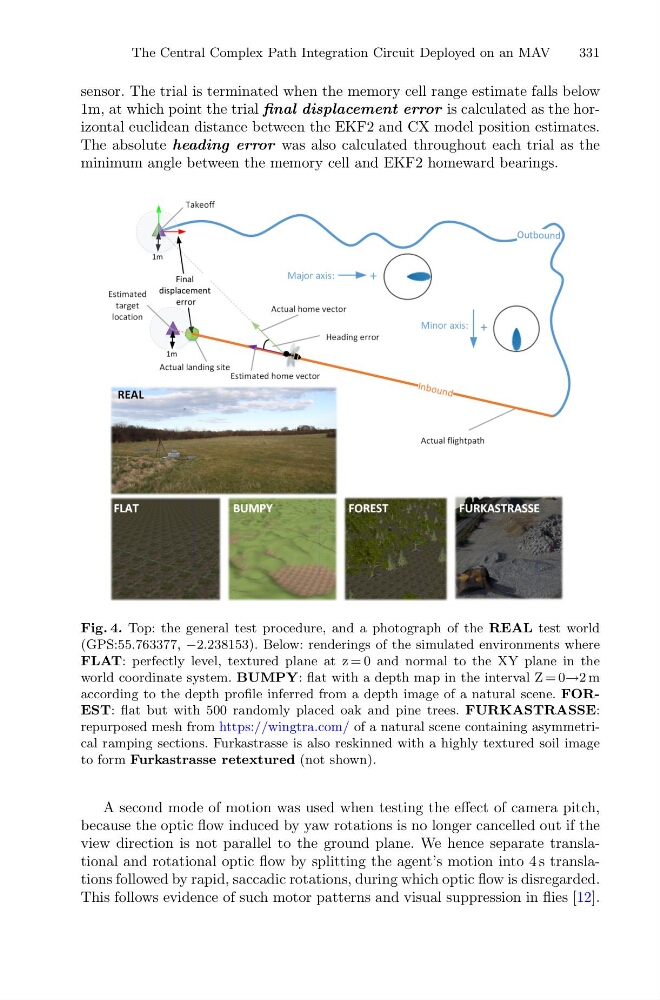
1m, at which point the trial final displacement error is calculated as the horizontal euclidean distance between the EKF2 and CX model position estimates.
The absolute heading error was also calculated throughout each trial as the
minimum angle between the memory cell and EKF2 homeward bearings.
Fig. 4. Top: the general test procedure, and a photograph of the REAL test world
(GPS:55.763377, −2.238153). Below: renderings of the simulated environments where
FLAT: perfectly level, textured plane at z = 0 and normal to the XY plane in the
world coordinate system. BUMPY: flat with a depth map in the interval Z = 0→2 m
according to the depth profile inferred from a depth image of a natural scene. FOREST: flat but with 500 randomly placed oak and pine trees. FURKASTRASSE:
repurposed mesh from https://wingtra.com/ of a natural scene containing asymmetrical ramping sections. Furkastrasse is also reskinned with a highly textured soil image
to form Furkastrasse retextured (not shown).
A second mode of motion was used when testing the effect of camera pitch,
because the optic flow induced by yaw rotations is no longer cancelled out if the
view direction is not parallel to the ground plane. We hence separate translational and rotational optic flow by splitting the agent’s motion into 4 s translations followed by rapid, saccadic rotations, during which optic flow is disregarded.
This follows evidence of such motor patterns and visual suppression in flies [12].