

The Central Complex Path Integration Circuit Deployed on an MAV
329
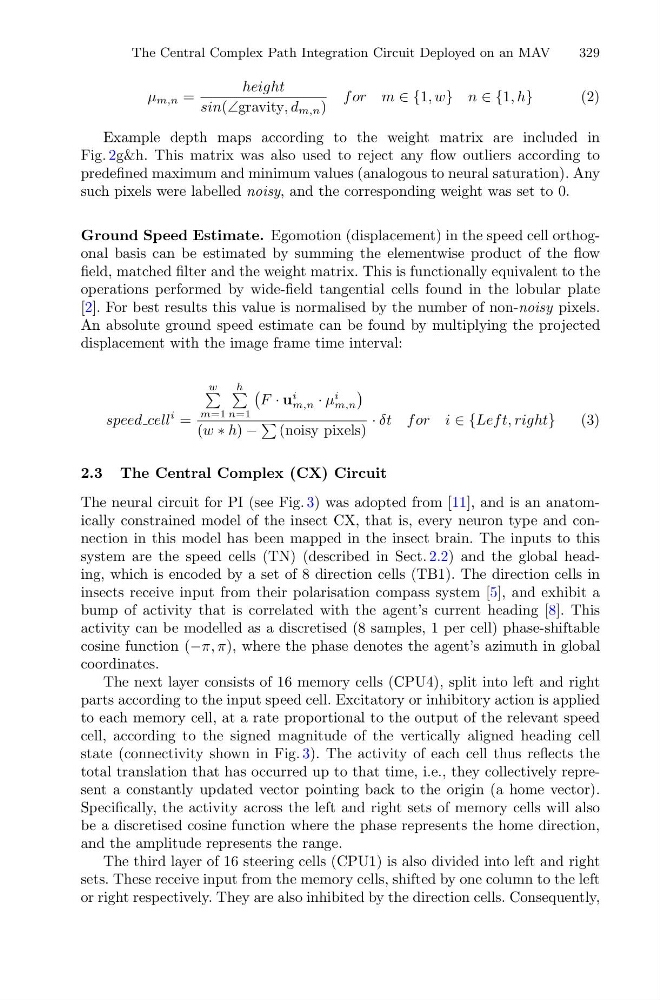
μ m,n =
height
sin(∠gravity, d m,n )
for m ∈ {1, w} n ∈ {1, h}
(2)
Example depth maps according to the weight matrix are included in
Fig. 2g&h. This matrix was also used to reject any flow outliers according to
predefined maximum and minimum values (analogous to neural saturation). Any
such pixels were labelled noisy, and the corresponding weight was set to 0.
Ground Speed Estimate. Egomotion (displacement) in the speed cell orthogonal basis can be estimated by summing the elementwise product of the flow
field, matched filter and the weight matrix. This is functionally equivalent to the
operations performed by wide-field tangential cells found in the lobular plate
[2]. For best results this value is normalised by the number of non-noisy pixels.
An absolute ground speed estimate can be found by multiplying the projected
displacement with the image frame time interval:
speed cell
i =
w
m=1
h
n=1
F · u
i
m,n · μ
i
m,n
(w ∗ h) −
(noisy pixels)
· δt f or i ∈ {Lef t, right}
(3)
2.3 The Central Complex (CX) Circuit
The neural circuit for PI (see Fig. 3) was adopted from [11], and is an anatomically constrained model of the insect CX, that is, every neuron type and connection in this model has been mapped in the insect brain. The inputs to this
system are the speed cells (TN) (described in Sect. 2.2) and the global heading, which is encoded by a set of 8 direction cells (TB1). The direction cells in
insects receive input from their polarisation compass system [5], and exhibit a
bump of activity that is correlated with the agent’s current heading [8]. This
activity can be modelled as a discretised (8 samples, 1 per cell) phase-shiftable
cosine function (−π, π), where the phase denotes the agent’s azimuth in global
coordinates.
The next layer consists of 16 memory cells (CPU4), split into left and right
parts according to the input speed cell. Excitatory or inhibitory action is applied
to each memory cell, at a rate proportional to the output of the relevant speed
cell, according to the signed magnitude of the vertically aligned heading cell
state (connectivity shown in Fig. 3). The activity of each cell thus reflects the
total translation that has occurred up to that time, i.e., they collectively represent a constantly updated vector pointing back to the origin (a home vector).
Specifically, the activity across the left and right sets of memory cells will also
be a discretised cosine function where the phase represents the home direction,
and the amplitude represents the range.
The third layer of 16 steering cells (CPU1) is also divided into left and right
sets. These receive input from the memory cells, shifted by one column to the left
or right respectively. They are also inhibited by the direction cells. Consequently,