

266
C. Morrow et al.
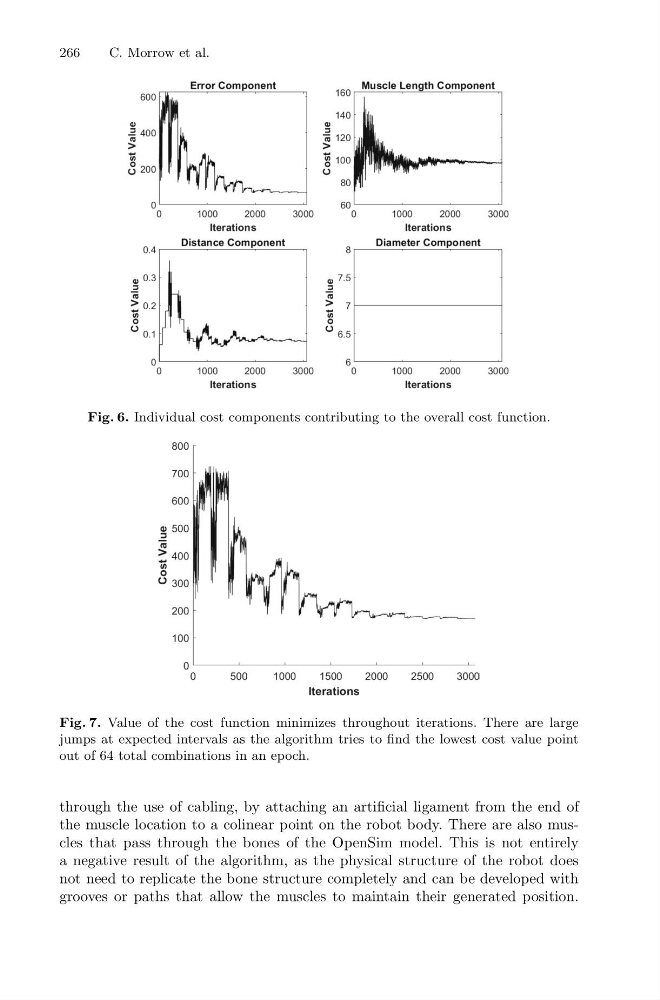
Fig. 6. Individual cost components contributing to the overall cost function.
Fig. 7. Value of the cost function minimizes throughout iterations. There are large
jumps at expected intervals as the algorithm tries to find the lowest cost value point
out of 64 total combinations in an epoch.
through the use of cabling, by attaching an artificial ligament from the end of
the muscle location to a colinear point on the robot body. There are also muscles that pass through the bones of the OpenSim model. This is not entirely
a negative result of the algorithm, as the physical structure of the robot does
not need to replicate the bone structure completely and can be developed with
grooves or paths that allow the muscles to maintain their generated position.