

Haptic Object Identification for Advanced Manipulation Skills
133
A single exploration step is thus given by selecting cell c
g , approaching this cell,
starting a measurement by e.g. applying a force upon the object and updating
the inference grid based on the new measurement.
3.2 Shape-Based Exploration
A major drawback of the grid-based framework is that the resolution of the grid
inevitably leads to uncertainties due to the discretization of the grid. Therefore,
we propose a second exploration approach which uses analytic shape representations of geometric primitives, namely spheres, cylinders, boxes and planes.
Provided initial data points from e.g. computer vision, we fit initial models that
generate a hypothesis for each model shape. As each model-fit is conditionally
independent from the others, each hypothesis forms a shape-particle S
i . All
shape-particles denoted as S t=0 form a Particle-Filter, where each particle is
associated with a belief, initialized by a uniform distribution over all particles.
In order to explore the environment efficiently, a utility metric is needed that
minimizes the uncertainty at each step, i.e. to distinguish between various shape
candidates. This selection boils down to finding the optimal contact point from
a set of candidates P = {p 1 , p 2 , . . . } representing possible contact points on a
surface of a shape-particle. Similar to (3), the utility metric is based on [12] and
the concept of mutual information [8]. We further assume a multivariate normaldistributed sensor-model with covariance Σ, such that the utility results in
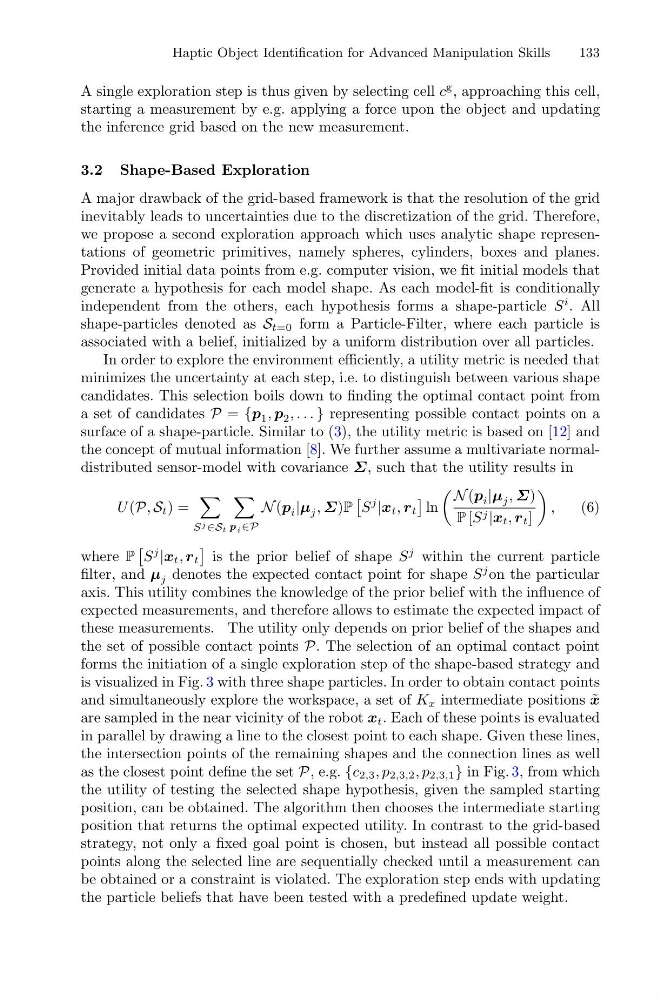
U (P, S t ) =
S j ∈St
p i ∈P
N (p i |μ j , Σ)P
S
j
|x t , r t
ln
N (p i |μ j , Σ)
P [S j |x t , r t ]
,
(6)
where P
S
j
|x t , r t
is the prior belief of shape S
j within the current particle
filter, and μ j denotes the expected contact point for shape S
j on the particular
axis. This utility combines the knowledge of the prior belief with the influence of
expected measurements, and therefore allows to estimate the expected impact of
these measurements. The utility only depends on prior belief of the shapes and
the set of possible contact points P. The selection of an optimal contact point
forms the initiation of a single exploration step of the shape-based strategy and
is visualized in Fig. 3 with three shape particles. In order to obtain contact points
and simultaneously explore the workspace, a set of K x intermediate positions ˜
x
are sampled in the near vicinity of the robot x t . Each of these points is evaluated
in parallel by drawing a line to the closest point to each shape. Given these lines,
the intersection points of the remaining shapes and the connection lines as well
as the closest point define the set P, e.g. {c 2,3 , p 2,3,2 , p 2,3,1 } in Fig. 3, from which
the utility of testing the selected shape hypothesis, given the sampled starting
position, can be obtained. The algorithm then chooses the intermediate starting
position that returns the optimal expected utility. In contrast to the grid-based
strategy, not only a fixed goal point is chosen, but instead all possible contact
points along the selected line are sequentially checked until a measurement can
be obtained or a constraint is violated. The exploration step ends with updating
the particle beliefs that have been tested with a predefined update weight.