

11 Meshless Algorithms for Computational Biomechanics of the Brain
295
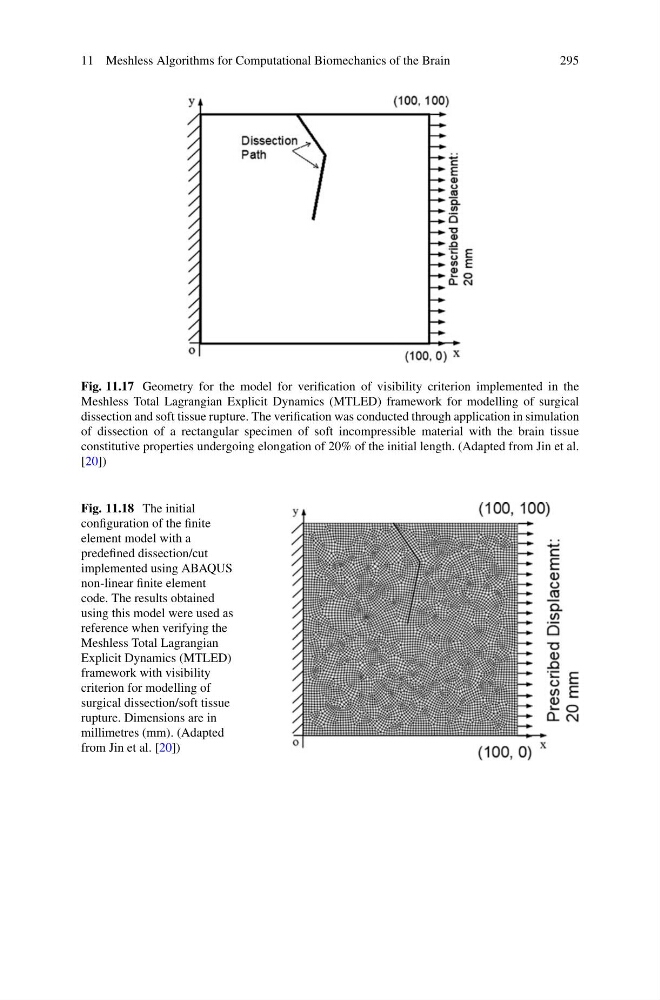
Fig. 11.17 Geometry for the model for verification of visibility criterion implemented in the
Meshless Total Lagrangian Explicit Dynamics (MTLED) framework for modelling of surgical
dissection and soft tissue rupture. The verification was conducted through application in simulation
of dissection of a rectangular specimen of soft incompressible material with the brain tissue
constitutive properties undergoing elongation of 20% of the initial length. (Adapted from Jin et al.
[20])
Fig. 11.18 The initial
configuration of the finite
element model with a
predefined dissection/cut
implemented using ABAQUS
non-linear finite element
code. The results obtained
using this model were used as
reference when verifying the
Meshless Total Lagrangian
Explicit Dynamics (MTLED)
framework with visibility
criterion for modelling of
surgical dissection/soft tissue
rupture. Dimensions are in
millimetres (mm). (Adapted
from Jin et al. [20])