

11 Meshless Algorithms for Computational Biomechanics of the Brain
275
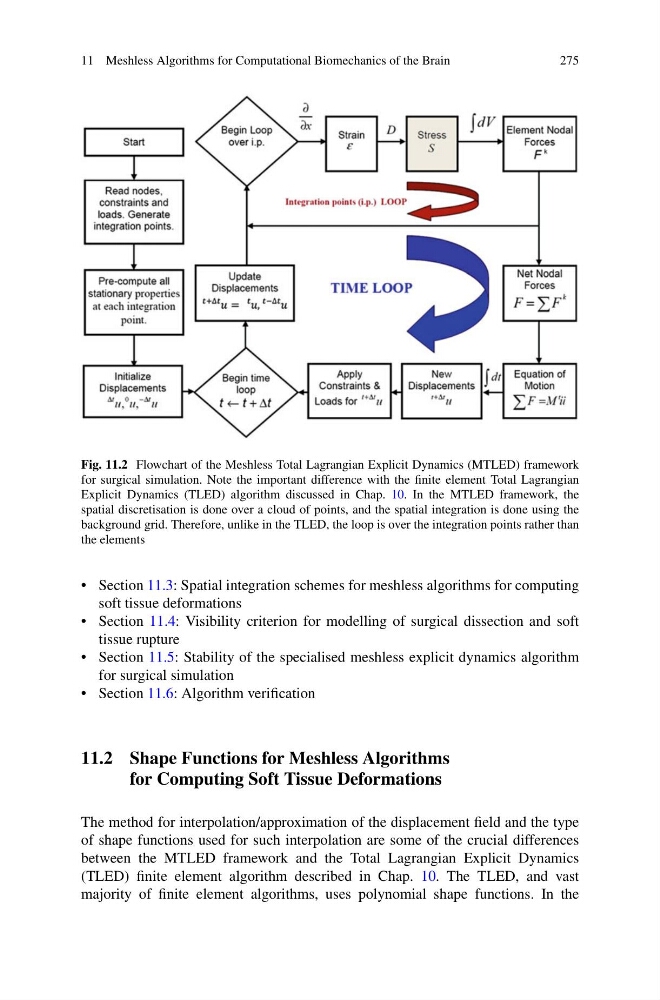
Fig. 11.2 Flowchart of the Meshless Total Lagrangian Explicit Dynamics (MTLED) framework
for surgical simulation. Note the important difference with the finite element Total Lagrangian
Explicit Dynamics (TLED) algorithm discussed in Chap. 10. In the MTLED framework, the
spatial discretisation is done over a cloud of points, and the spatial integration is done using the
background grid. Therefore, unlike in the TLED, the loop is over the integration points rather than
the elements
• Section 11.3: Spatial integration schemes for meshless algorithms for computing
soft tissue deformations
• Section 11.4: Visibility criterion for modelling of surgical dissection and soft
tissue rupture
• Section 11.5: Stability of the specialised meshless explicit dynamics algorithm
for surgical simulation
• Section 11.6: Algorithm verification
11.2 Shape Functions for Meshless Algorithms
for Computing Soft Tissue Deformations
The method for interpolation/approximation of the displacement field and the type
of shape functions used for such interpolation are some of the crucial differences
between the MTLED framework and the Total Lagrangian Explicit Dynamics
(TLED) finite element algorithm described in Chap. 10. The TLED, and vast
majority of finite element algorithms, uses polynomial shape functions. In the