

6 Biomechanical Modelling of the Brain for Neurosurgical Simulation. . .
143
the volumetric response (e.g. Poisson’s ratio) is of minor consequence for soft
organ biomechanics because tissues such as the brain, liver, kidney or prostate are
considered almost incompressible; see, e.g. Chap. 4 of this book and [53–55].
In the general non-linear case, the displacement results will still remain insensitive to the stress parameter appearing in the non-linear material law but may depend
on the particular form of that law (as the functional form of a constitutive law does
not have a dimension). However, this dependency will be rather weak, as explicitly
demonstrated in [56, 57] where the shapes of compressed and extended cylinders
were shown to be essentially independent of the material law used for the cylinder’s
material; see Fig. 6.7. These results suggest a move away from mechanics towards
kinematics where the main quantities of interest in this approach are displacements,
strains and their histories.
We now consider nonrigid image registration in image-guided procedures where
high-resolution pre-operative scans are warped onto lower-quality intra-operative
images [58, 59]. The task of particular clinical interest is registering high-resolution
pre-operative MRIs with lower-quality intra-operative imaging modalities, such as
intra-operative ultrasound and multiplanar MRIs.
The brain, for which a detailed pre-operative image is available, deforms after
craniotomy due to several physical and physiological reasons (i.e. brain shift,
the specific mechanisms of the brain shift include decompression, response to
anaesthesia and other possible and hotly contested phenomena). We are interested in
the intra-operative (i.e. current) position of the brain, for which partial information
is provided by low-resolution intra-operative images. In mathematical terms this
problem can be described with equations of solid mechanics.
Consider the motion of a deforming body in a stationary coordinate system,
Fig. 6.8. In the analysis we follow the motion of all particles from their original
position to the final configuration of the body, which means that the Lagrangian (or
material) formulation of the problem is adopted. Motion of the system sketched in
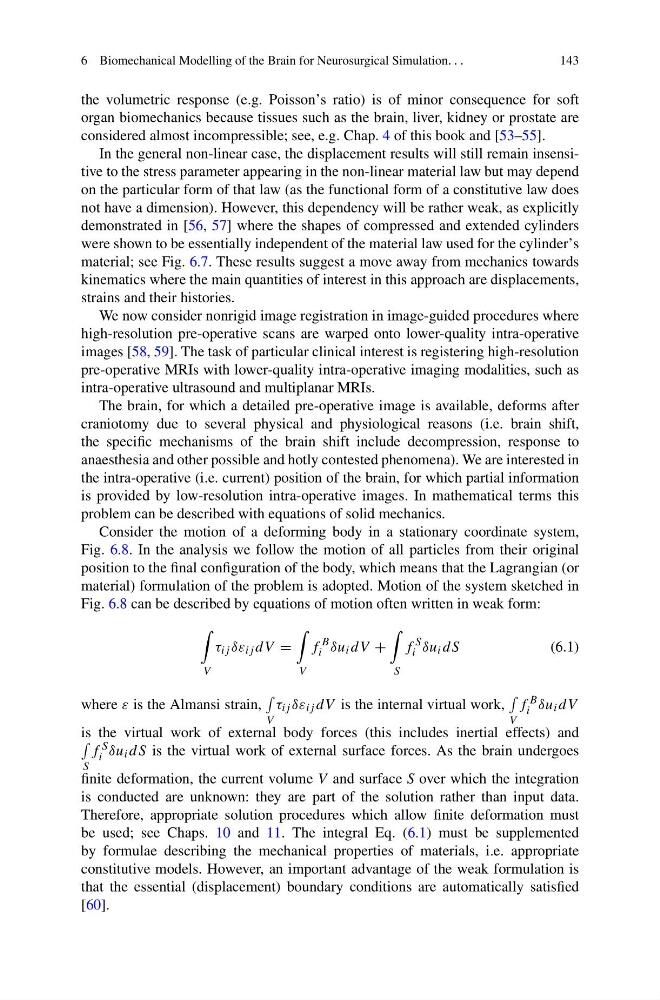
Fig. 6.8 can be described by equations of motion often written in weak form:
V
τ ij δε ij dV =
V
f
B
i δu i dV +
S
f
S
i δu i dS
(6.1)
where ε is the Almansi strain,
V
τ ij δε ij dV is the internal virtual work,
V
f B
i δu i dV
is the virtual work of external body forces (this includes inertial effects) and
S
f S
i δu i dS is the virtual work of external surface forces. As the brain undergoes
finite deformation, the current volume V and surface S over which the integration
is conducted are unknown: they are part of the solution rather than input data.
Therefore, appropriate solution procedures which allow finite deformation must
be used; see Chaps. 10 and 11. The integral Eq. (6.1) must be supplemented
by formulae describing the mechanical properties of materials, i.e. appropriate
constitutive models. However, an important advantage of the weak formulation is
that the essential (displacement) boundary conditions are automatically satisfied
[60].