

DEPLOYMENT OF AN OTEC PIPELINE
275
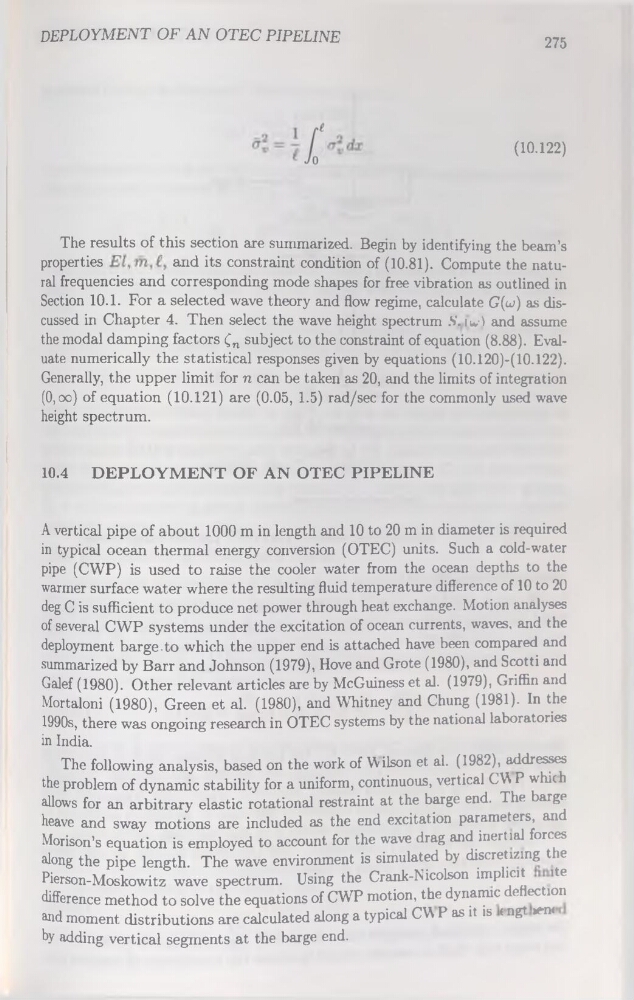
(10.122)
The results of this section are summarized. Begin by identifying the beam’s
properties
and its constraint condition of (10.81). Compute the natural frequencies and corresponding mode shapes for free vibration as outlined in
Section 10.1. For a selected wave theory and flow régime, calculate G(w) as discussed in Chapter 4. Then select the wave height spectrum ,S’. iwi and assume
the modal damping factors Çn subject to the constraint of équation (8.88). Evaluate numerically the statistical responses given by équations (10.120)-(10.122).
Generally, the upper limit for n can be taken as 20, and the limits of intégration
(0, oo) of équation (10.121) are (0.05, 1.5) rad/sec for the commonly used wave
height spectrum.
10.4 DEPLOYMENT OF AN OTEC PIPELINE
A vertical pipe of about 1000 m in length and 10 to 20 m in diameter is required
in typical océan thermal energy conversion (OTEC) units. Such a cold-water
pipe (CWP) is used to raise the cooler water from the océan depths to the
warmer surface water where the resulting fluid température différence of 10 to 20
deg C is sufficient to produce net power through heat exchange. Motion analyses
of several CWP Systems under the excitation of océan currents, waves, and the
deployment barge, to which the upper end is attached hâve been compared and
summarized by Barr and Johnson (1979), Hove and Grote (1980), and Scotti and
Galef (1980). Other relevant articles are by McGuiness et al. (1979), Griffin and
Mortaloni (1980), Green et al. (1980), and Whitney and Chung (1981). In the
1990s, there was ongoing research in OTEC Systems by the national laboratories
in India.
The following analysis, based on the work of Wilson et al. (1982), addresses
the problem of dynamic stability for a uniform, continuons, vertical CW P which
allows for an arbitrary elastic rotational restraint at the barge end. The barge
heave and sway motions are included as the end excitation parameters, and
Morison’s équation is employed to account for the wave drag and inertial forces
along the pipe length. The wave environment is simulated by discretizing the
Pierson-Moskowitz wave spectrum. Using the Crank-Nicolson implicit
ite
différence method to solve the équations of CWP motion, the dynamic deflection
and moment distributions are calculated along a typical CW P as it is ( ngt »en<
by adding vertical segments at the barge end.