

CABLE RESPONSES
261
Parametric Excitation
Longitudinal or parametric excitation of a relatively taut cable is depicted
in Figure 10.1b. This type of excitation may also occur in the vertical lines or
chains shown in Figures 10.6 when the ship or buoy undergoes heave motion in
regular waves. In such cases the average cable tension is Po, the amplitude of
the harmonically fluctuating force is P^ < Po, and the excitation frequency is
w. Parametric excitation is thus defined as
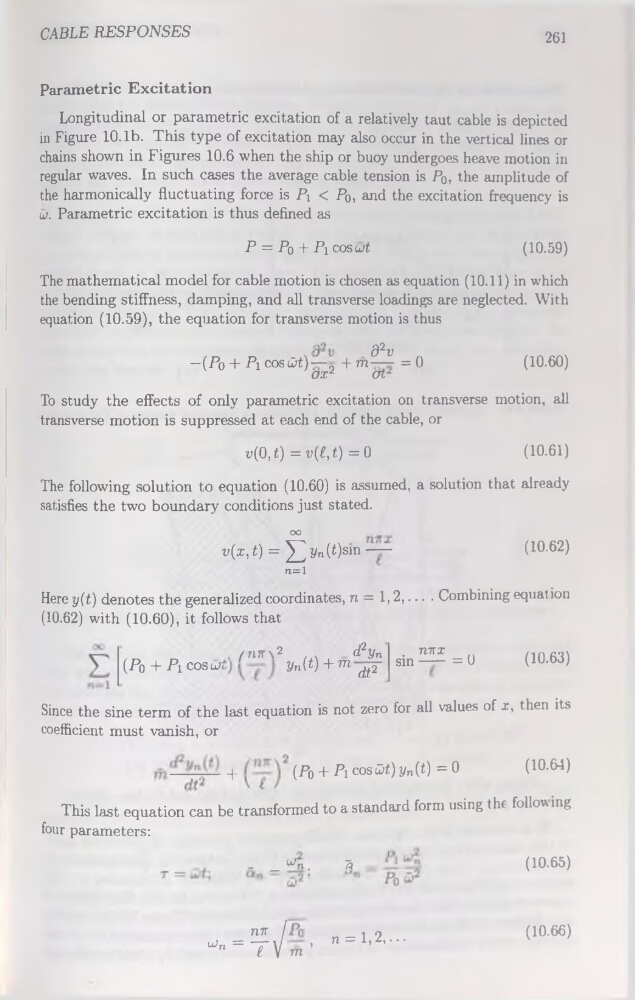
P = Pq + Pi coswt
(10.59)
The mathematical model for cable motion is chosen as équation (10.11) in which
the bending stiffness, damping, and ail transverse loadings are neglected. With
équation (10.59), the équation for transverse motion is thus
d2v
-(Po + PiCOSlût)—2+m—=0
(10.60)
or,
atr
To study the effects of only parametric excitation on transverse motion, ail
transverse motion is suppressed at each end of the cable, or
v(0,t) =v(e,t) =0
(10.61)
The following solution to équation (10.60) is assumed, a solution that already
satisfies the two boundary conditions just stated.
oo
v^t) = ^yn^m~
(10-62)
n=l
Here y(t) dénotés the generalized coordinates, n = 1,2,... . Combining équation
(10.62) with (10.60), it follows that
(10.63)
then its
+
(Fo + Fi cosûf) yn(t) = 0
(10.64)
This last équation can be transformed to a standard form using the following
four parameters:
- _^n.
s
'
(10.65)
n = l,2,...
t10-66)
m '
nitx
sin —— = 0
(Po + PiCOSW)
. /nJTX2
/m ,
yn(t) + m^
Since the sine term of the last équation is not zéro for ail values of x,
coefficient must vanish, or