

characterize the spatial complexity recorded in raw satellite images (Lam, 1990; Read
and Lam, 2002; Weng, 2003; Qiu et al., 1999), to examine the spatial patterns
involved in land use/land cover (LULC) classified images (De Cola, 1989), to assist in
image classification (Myint, 2003; Emerson et al., 2005), and to study the scaling
effect of remotely sensed images (Emerson et al., 1999; Myint, 2003).
To successfully apply FD in remote sensing, the most critical step is the selection
of many algorithms to calculate the FD of imagery. All algorithms were developed
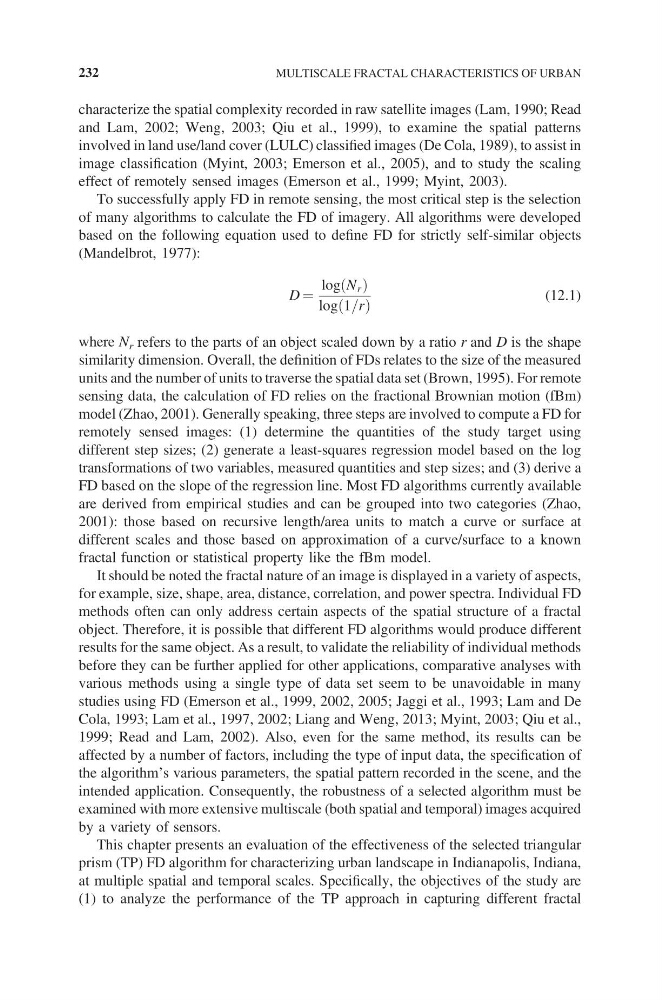
based on the following equation used to define FD for strictly self-similar objects
(Mandelbrot, 1977):
D =
log N r
log 1=r
(12.1)
where N r refers to the parts of an object scaled down by a ratio r and D is the shape
similarity dimension. Overall, the definition of FDs relates to the size of the measured
units and the number of units to traverse the spatial data set (Brown, 1995). For remote
sensing data, the calculation of FD relies on the fractional Brownian motion (fBm)
model (Zhao, 2001). Generally speaking, three steps are involved to compute a FD for
remotely sensed images: (1) determine the quantities of the study target using
different step sizes; (2) generate a least-squares regression model based on the log
transformations of two variables, measured quantities and step sizes; and (3) derive a
FD based on the slope of the regression line. Most FD algorithms currently available
are derived from empirical studies and can be grouped into two categories (Zhao,
2001): those based on recursive length/area units to match a curve or surface at
different scales and those based on approximation of a curve/surface to a known
fractal function or statistical property like the fBm model.
It should be noted the fractal nature of an image is displayed in a variety of aspects,
for example, size, shape, area, distance, correlation, and power spectra. Individual FD
methods often can only address certain aspects of the spatial structure of a fractal
object. Therefore, it is possible that different FD algorithms would produce different
results for the same object. As a result, to validate the reliability of individual methods
before they can be further applied for other applications, comparative analyses with
various methods using a single type of data set seem to be unavoidable in many
studies using FD (Emerson et al., 1999, 2002, 2005; Jaggi et al., 1993; Lam and De
Cola, 1993; Lam et al., 1997, 2002; Liang and Weng, 2013; Myint, 2003; Qiu et al.,
1999; Read and Lam, 2002). Also, even for the same method, its results can be
affected by a number of factors, including the type of input data, the specification of
the algorithm’s various parameters, the spatial pattern recorded in the scene, and the
intended application. Consequently, the robustness of a selected algorithm must be
examined with more extensive multiscale (both spatial and temporal) images acquired
by a variety of sensors.
This chapter presents an evaluation of the effectiveness of the selected triangular
prism (TP) FD algorithm for characterizing urban landscape in Indianapolis, Indiana,
at multiple spatial and temporal scales. Specifically, the objectives of the study are
(1) to analyze the performance of the TP approach in capturing different fractal
232
MULTISCALE FRACTAL CHARACTERISTICS OF URBAN